
PAL Robotics
PAL TALOS
Torque-controlled biped research humanoid from Barcelona-based PAL Robotics: 175 cm, 95 kg, 32 DoF, 6 kg per arm fully extended, ROS-based software.
Catalog dataAvailableBipedal humanoidPublic SDK
- Height
- 1.75 m
- Mass
- 95 kg
- Total DoF
- 32
- Payload
- 6 kg
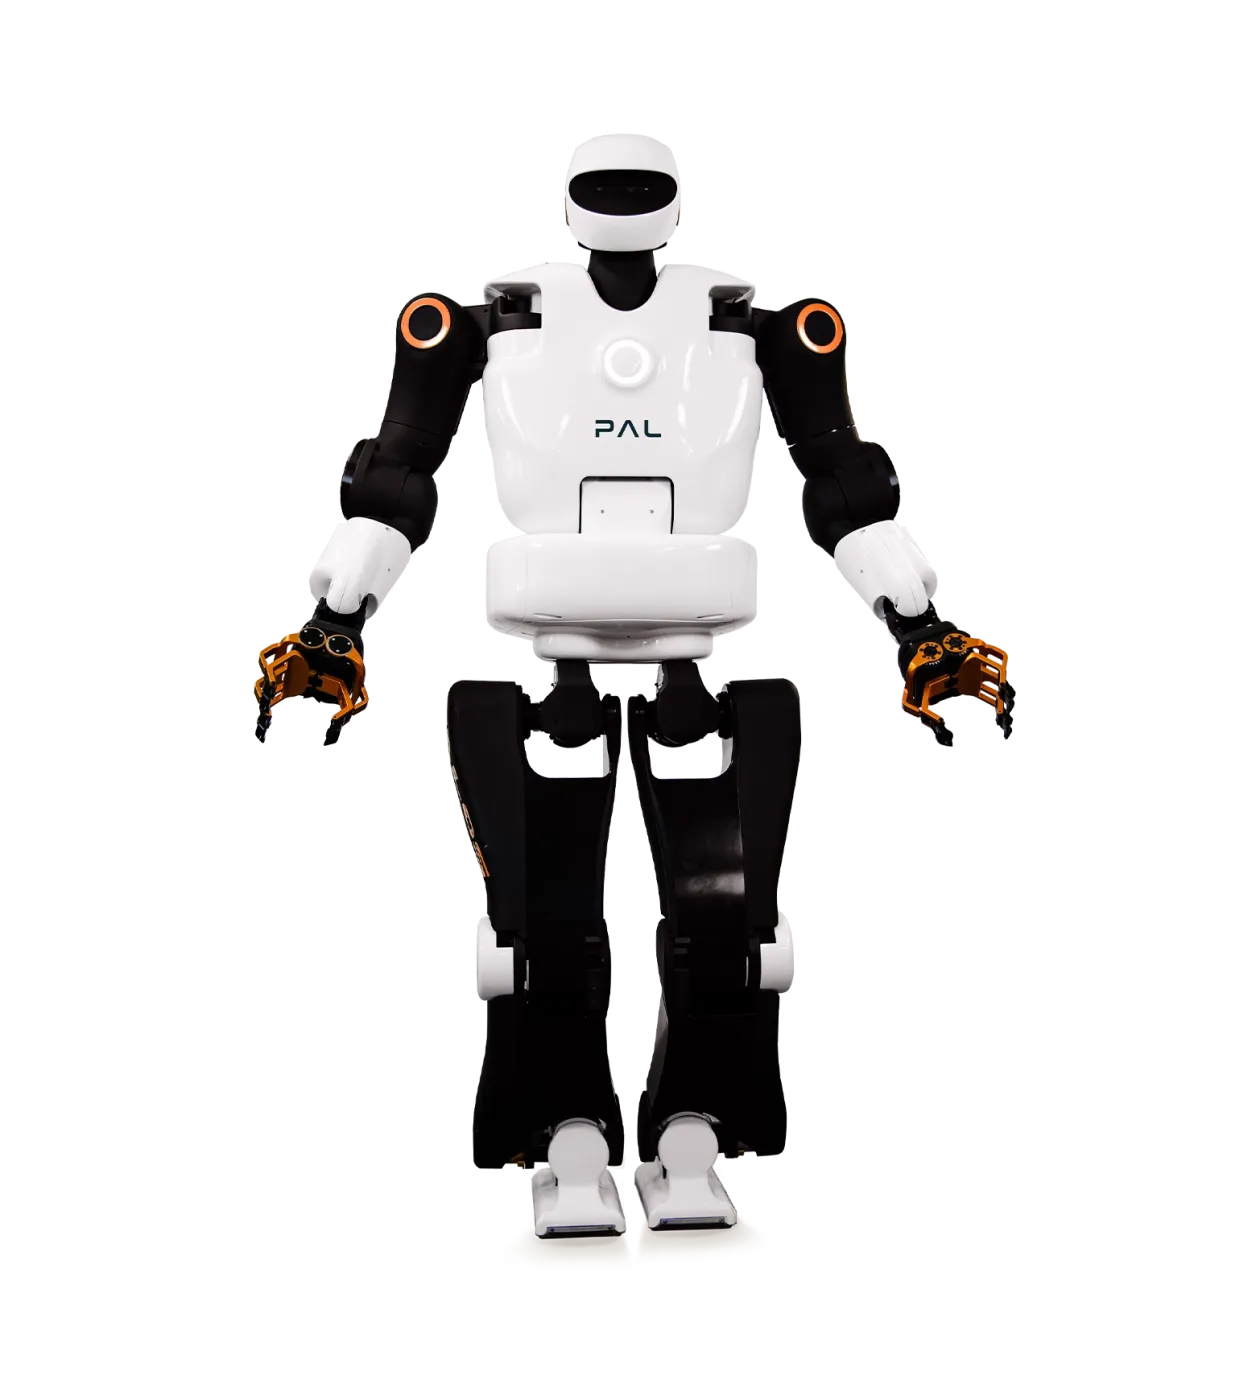 Image: © PAL Robotics
ARworks
ARworks status by function
What works with this robot at ARworks today – and what does not.
Catalog data No ARworks integration for this robot: catalog data only. Integration follows a per-robot assessment.
PAL TALOS
Technical data
From manufacturer or primary sources. The superscript points to the source.
Actuators and hands
Sensing and compute
| Vision | RGB (1280×720 at 30 fps) and depth (640×480 at 30 fps, 0.4–8 m); FOV 60°×49.5° (73° diagonal); head with 150° pan range2 |
|---|---|
| Other sensing | 4× 6-axis F/T sensors (ankles and wrists); joint torque sensors; AHRS IMU (1 kHz); encoders and temperature sensors2 |
| Onboard compute | 2× Intel Core i7 (control and multimedia PC, COM Express Type-6); Ubuntu LTS, Linux RT Preempt2 |
Energy and connectivity
Development
| SDK / API | ROS and OROCOS middleware, real-time ros_control loop (+1 kHz), MoveIt! planning2 |
|---|---|
| Robot description files | URDF with CoM position, mass and inertia tensors (extracted from CAD, validated)1 |
| Simulation | Gazebo simulation and URDF model; open-source simulation model2 |
| License | talos_robot ROS packages (description, controller configuration) are Apache-2.03 |
Size
Editorial notes
- Per the maker’s datasheet, the 32 DoF include the two grippers and the neck.
Sources
- TALOS | High-Performance Humanoid Robot — PAL Robotics · checked 2026-11-17
- TALOS – High Payload Humanoid Robot, technical specifications (datasheet, linked from pal-robotics.com/datasheet/talos/) — PAL Robotics · checked 2026-11-17
- pal-robotics/talos_robot — PAL Robotics · checked 2026-11-17
- pal-robotics/talos_simulation — PAL Robotics · checked 2026-11-17
Data sheet last checked: 2026-11-17 · Spain · Manufacturer names and images belong to their owners. Being listed in the catalog implies no partnership or integration.
Start a project
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.