
Humanoid robots, with checked data
13 models from manufacturer or primary sources. Every value is tied to a source and a check date; what the maker does not publish shows as “Not published”.
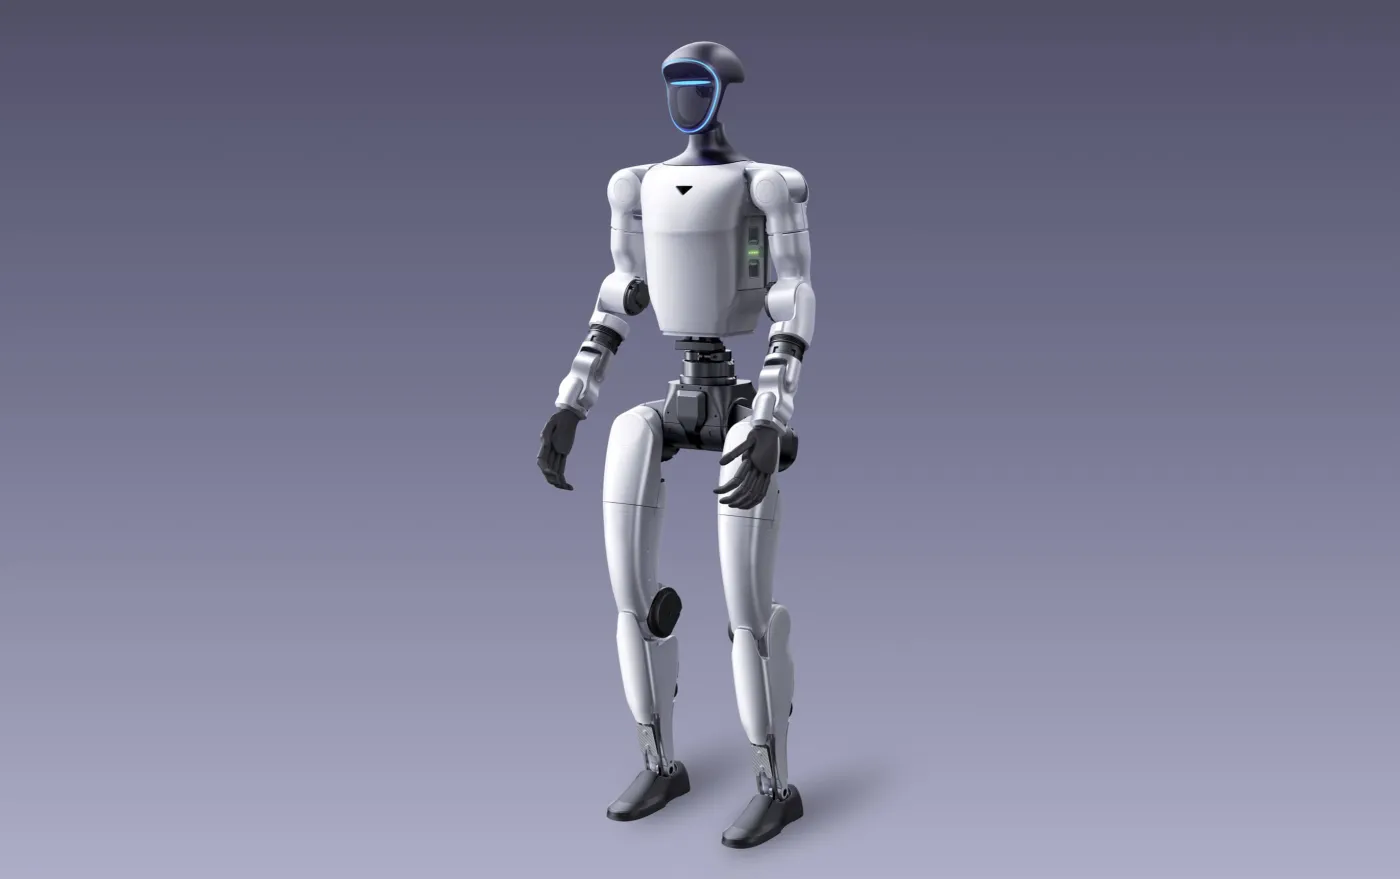 Image: © Unitree RoboticsSimulatedAvailable
Unitree G1
Unitree's 1.32 m, about 35 kg biped humanoid. Base G1 has 23 DoF; G1 EDU has 23–43 DoF, optional Dex3-1 hands and a Jetson Orin development unit.
- Height
- 1.32 m
- Mass
- 35 kg
- DoF
- 23
Bipedal humanoid · Public SDK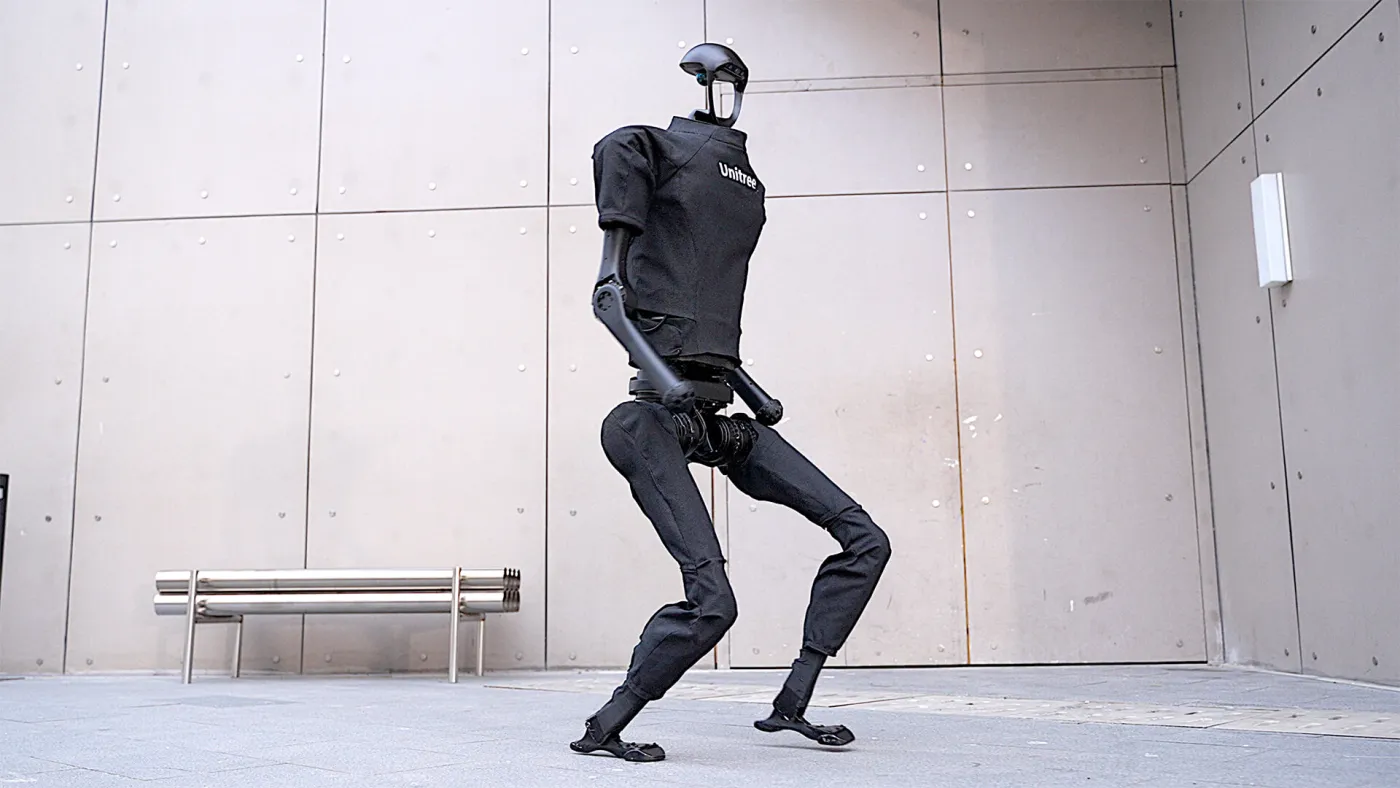 Image: © Unitree RoboticsCatalog dataAvailable
Unitree H1
Unitree's first full-size biped humanoid (about 1.8 m, 47 kg, 19 DoF). H1-2 adds 7-DoF arms and 6-DoF legs: 27 DoF, about 70 kg.
- Height
- 1.8 m
- Mass
- 47 kg
- DoF
- 19
Bipedal humanoid · Public SDK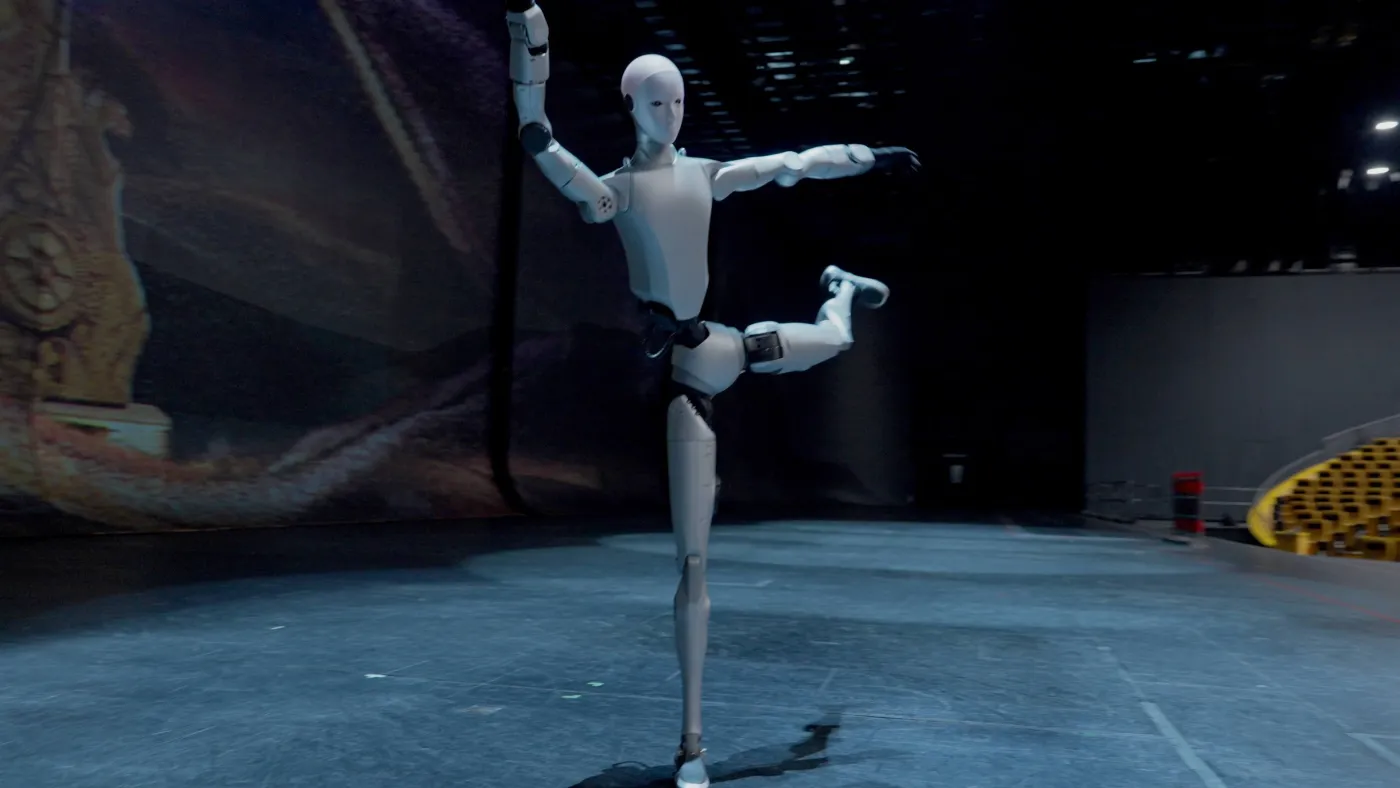 Image: © Unitree RoboticsCatalog dataAvailable
Unitree H2
Unitree's 1.82 m, about 70 kg full-size biped humanoid with 31 DoF (including a 2-DoF head) and a wide-FOV binocular head camera; EDU version available.
- Height
- 1.82 m
- Mass
- 70 kg
- DoF
- 31
Bipedal humanoid · Public SDK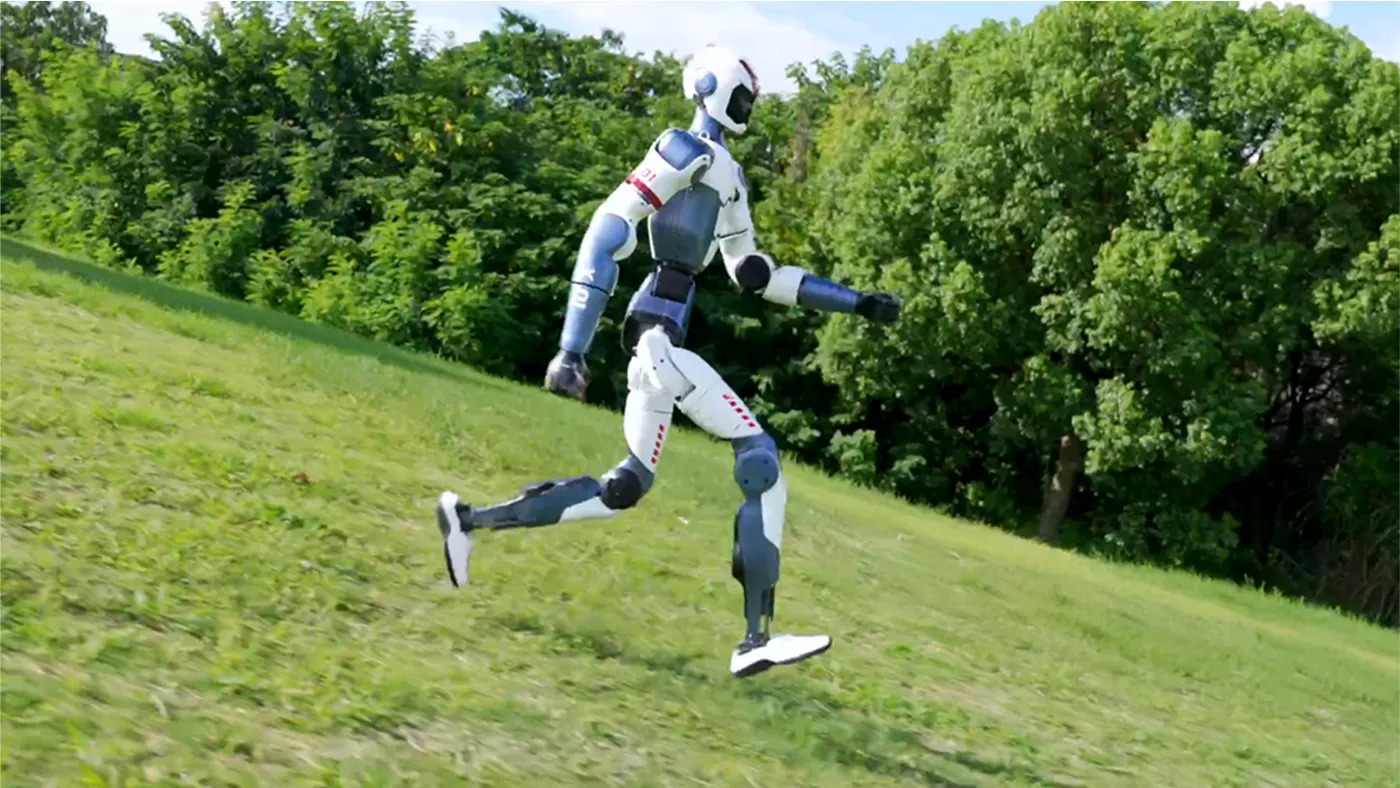 Image: © Unitree RoboticsCatalog dataAvailable
Unitree R1
Unitree's lightweight 1.23 m, about 27–29 kg biped humanoid in three versions: R1 Air (20 DoF), R1 (26 DoF) and R1 EDU (26–40 DoF, developer options).
- Height
- 1.23 m
- Mass
- 27 kg
- DoF
- 20
Bipedal humanoid · Public SDK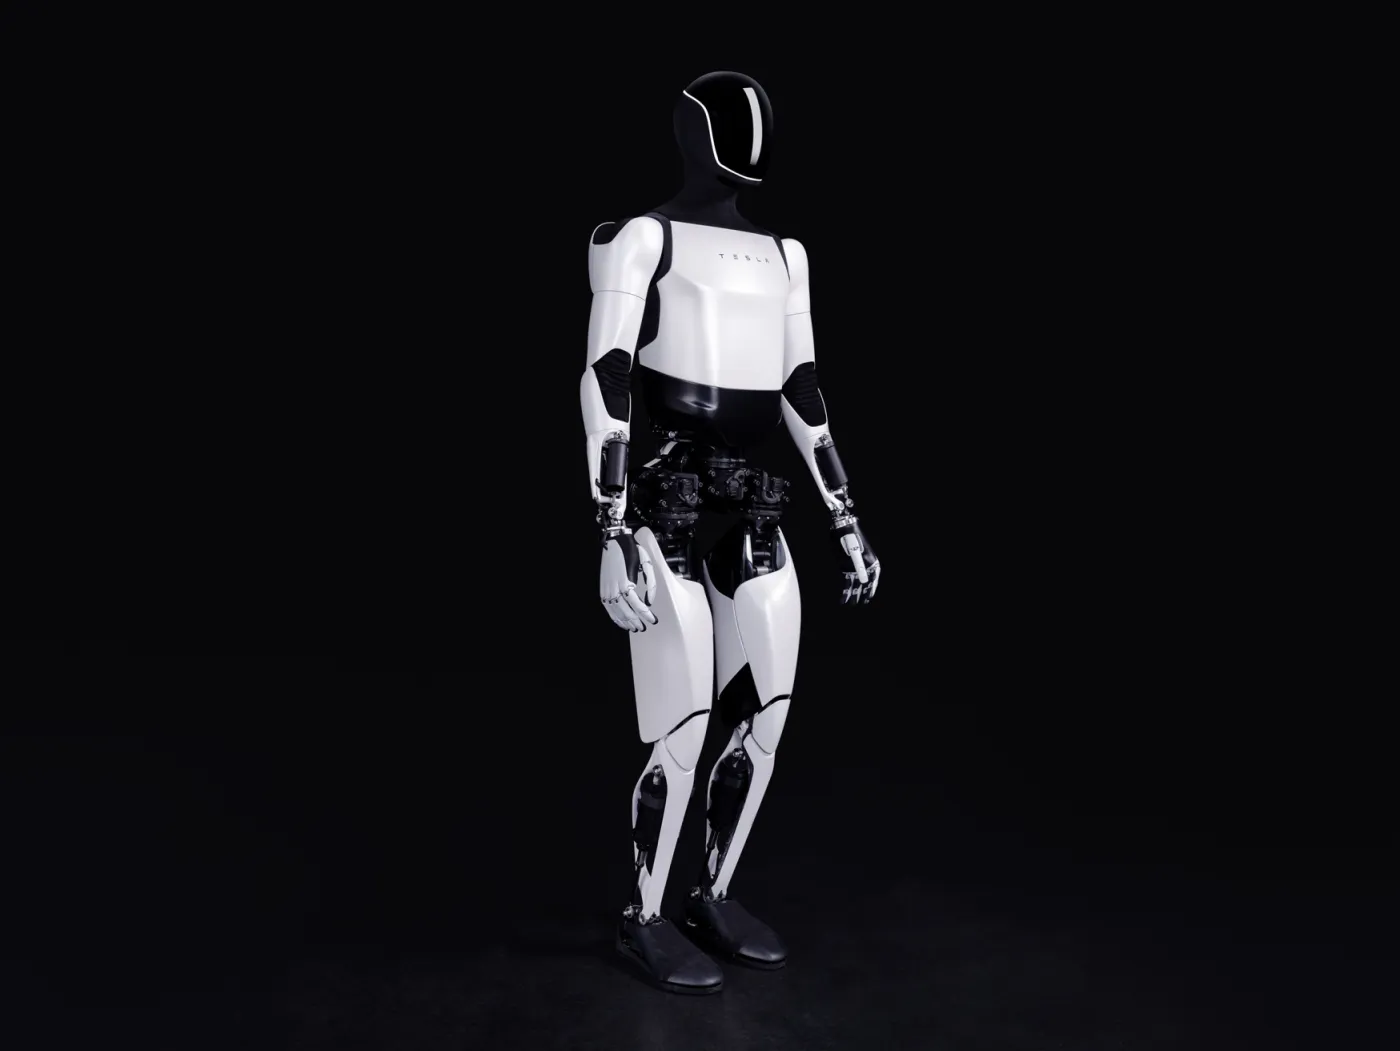 Image: © Tesla, Inc.3D modelAnnounced
Tesla Optimus
Described by Tesla as a general-purpose, bipedal, autonomous humanoid for unsafe, repetitive or boring tasks. Tesla reported production start in Fremont in Q3 2026; it publishes no technical specifications.
- Height
- Not published
- Mass
- Not published
- DoF
- Not published
Bipedal humanoid · No public SDK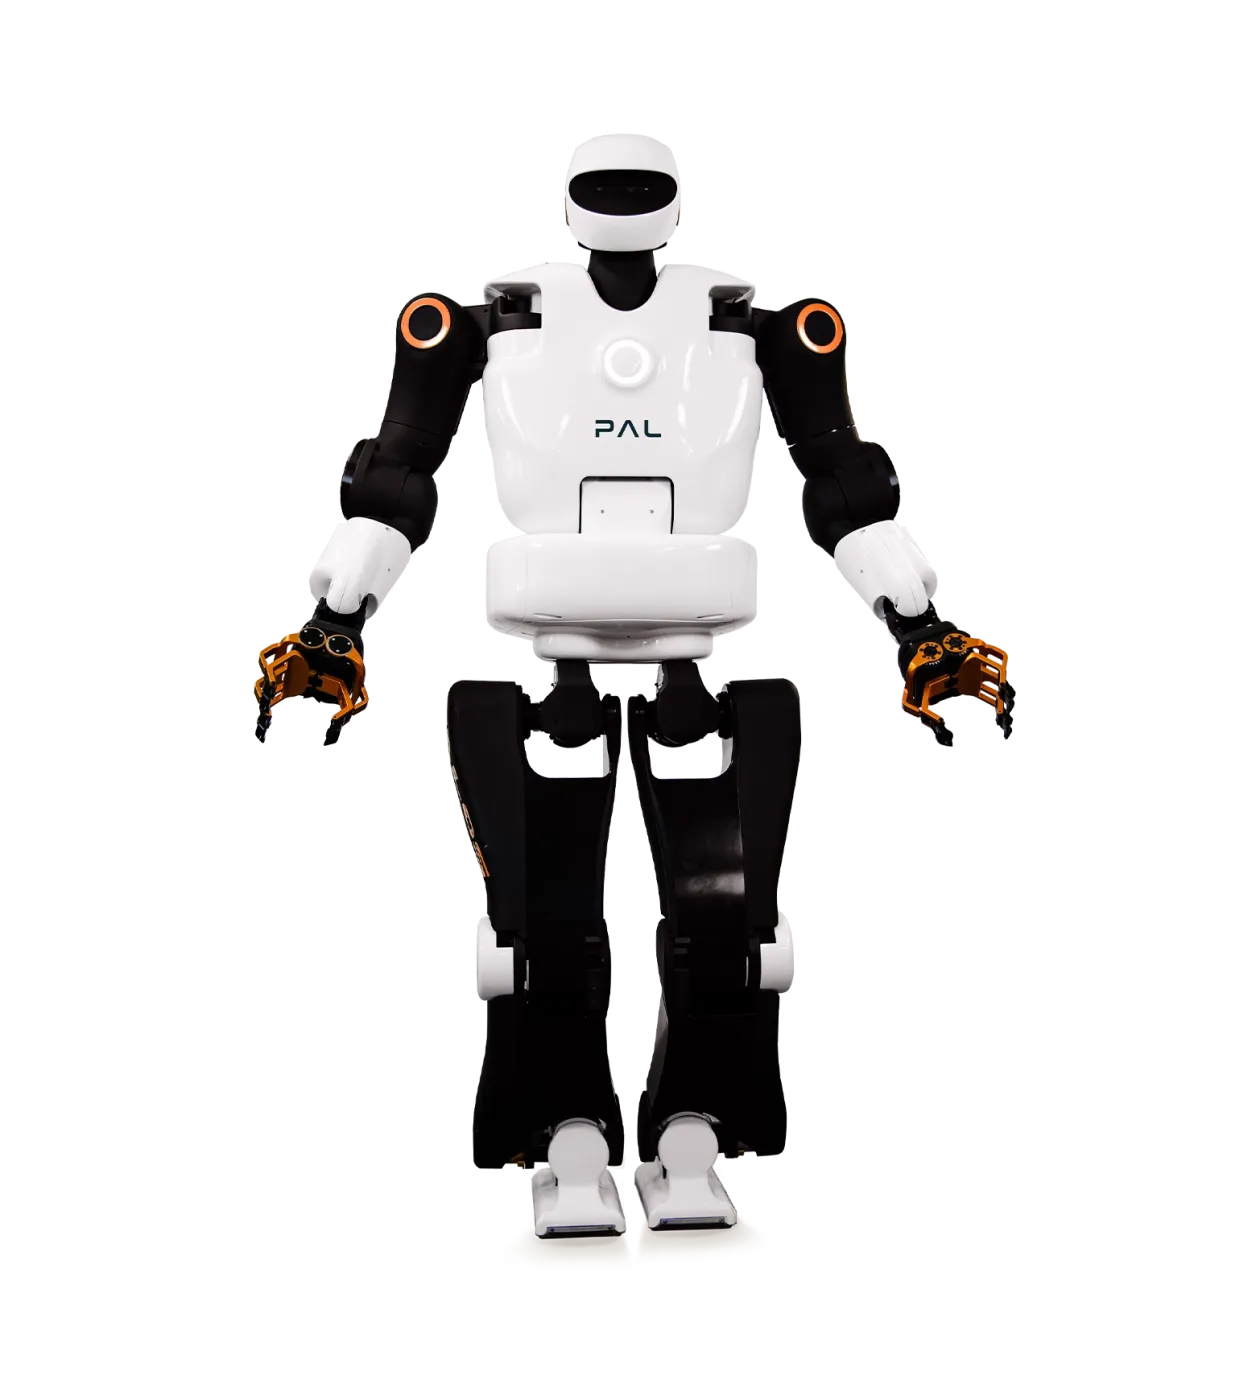 Image: © PAL RoboticsCatalog dataAvailable
PAL TALOS
Torque-controlled biped research humanoid from Barcelona-based PAL Robotics: 175 cm, 95 kg, 32 DoF, 6 kg per arm fully extended, ROS-based software.
- Height
- 1.75 m
- Mass
- 95 kg
- DoF
- 32
Bipedal humanoid · Public SDK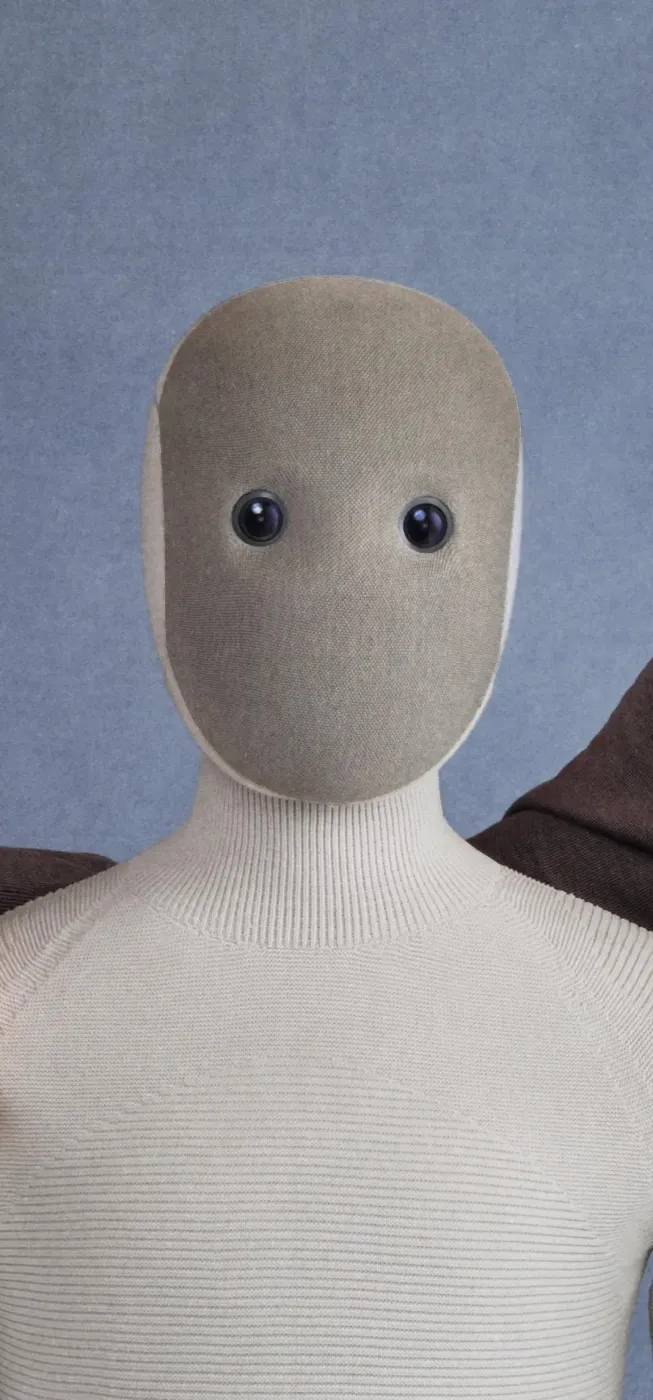 Image: © 1X TechnologiesCatalog dataPre-order
1X NEO
Home humanoid from 1X (San Carlos, California): tendon-driven actuators, soft body, 22-DoF hands, built-in language model; on preorder; per the maker, US deliveries start in 2026.
- Height
- 1.68 m
- Mass
- 30 kg
- DoF
- Not published
Bipedal humanoid · No public SDK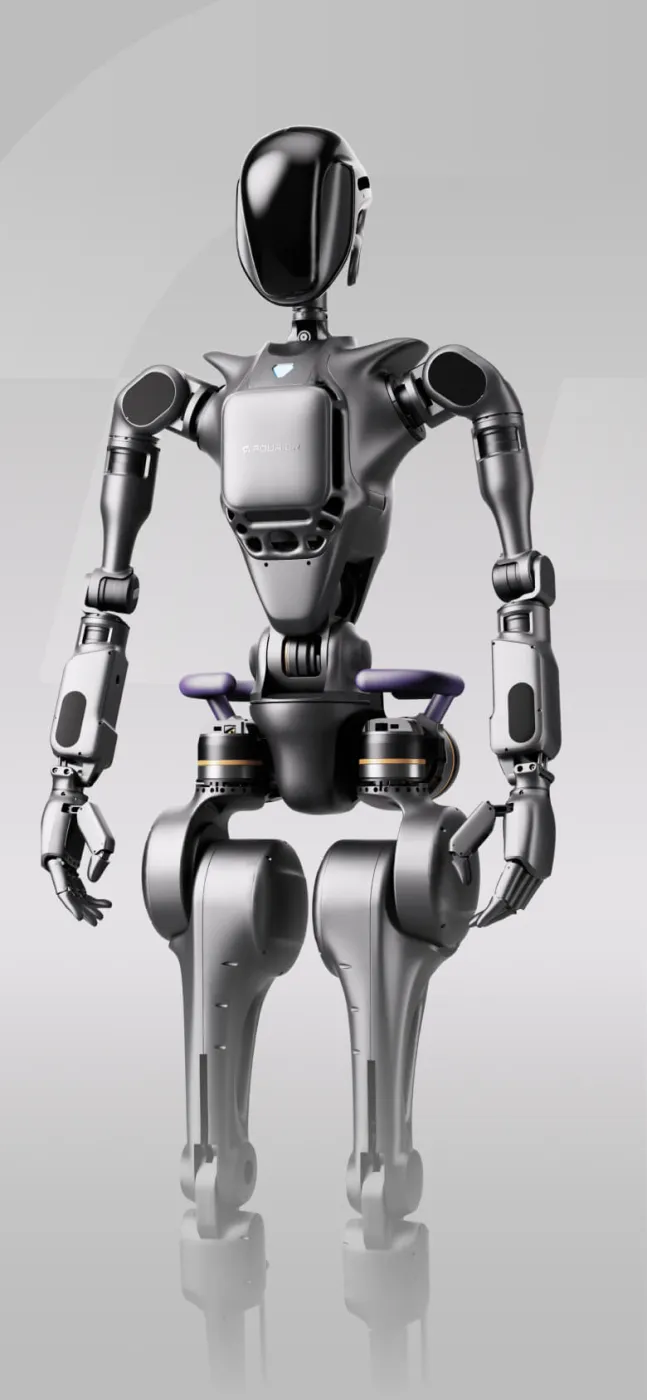 Image: © FourierCatalog dataDiscontinued
Fourier GR-1
Fourier's first-generation biped humanoid (1.65 m, approx. 52 kg) with up to 44 DoF, FSA actuators and 6-DoF dexterous hands; no longer in the current product line-up.
- Height
- 1.65 m
- Mass
- 52 kg
- DoF
- 44
Bipedal humanoid · Public SDK Image: © FourierCatalog dataAvailable
Fourier N1
Fourier's open-source 1.3 m, 38 kg biped research humanoid; 23 DoF with no hand joints, built for walking, running and stair climbing in locomotion research.
- Height
- 1.3 m
- Mass
- 38 kg
- DoF
- 23
Bipedal humanoid · Open source Image: © OpenLoong (openloong.org.cn)Catalog dataResearch platform
OpenLoong Qinglong
Open-source full-size (1.85 m, 80 kg) humanoid reference platform with 43 active DoF; its hardware drawings, control software and datasets are published by the OpenLoong community.
- Height
- 1.85 m
- Mass
- 80 kg
- DoF
- 43
Bipedal humanoid · Open source Image: © Hybrid Robotics, UC Berkeley (CC BY-SA 4.0)Catalog dataResearch platform
Berkeley Humanoid Lite
Open-source 0.8 m, 16 kg research humanoid from UC Berkeley with 3D-printed cycloidal gearboxes and off-the-shelf parts; the authors state a hardware cost under USD 5,000.
- Height
- 0.8 m
- Mass
- 16 kg
- DoF
- Not published
Bipedal humanoid · Open source Image: © ToddlerBot, Stanford UniversityCatalog dataResearch platform
ToddlerBot
Open-source 0.56 m, 3.4 kg miniature humanoid from Stanford University; 30 active DoF, Dynamixel servos, 3D-printed body, built for machine-learning research on loco-manipulation.
- Height
- 0.56 m
- Mass
- 3.4 kg
- DoF
- 30
Bipedal humanoid · Open source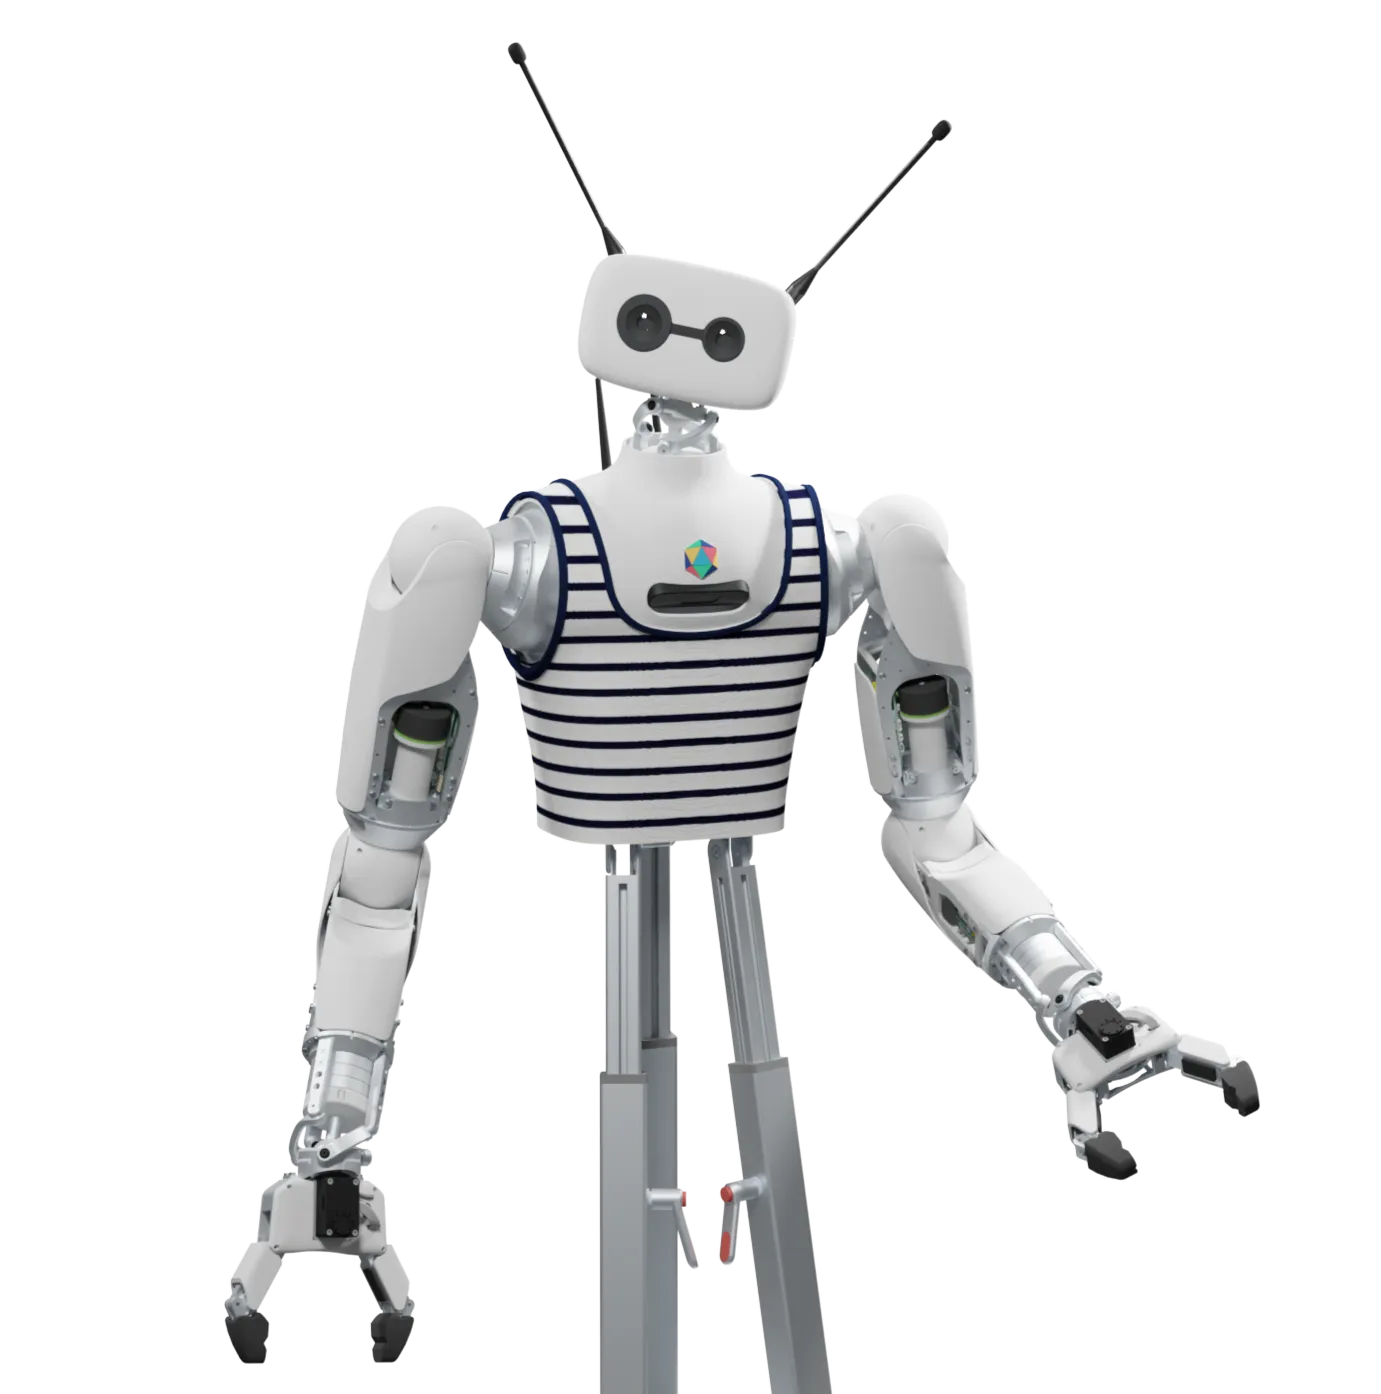 Image: © Pollen RoboticsCatalog dataAvailable
Pollen Reachy 2
Open-source bimanual humanoid upper body on an omnidirectional mobile base from Pollen Robotics (Hugging Face): 7-DoF arms, Python SDK, ROS 2 Humble, VR teleoperation.
- Height
- 1.36–1.66 m
- Mass
- 50 kg
- DoF
- Not published
Wheeled base, humanoid upper body · Open source
Manufacturer names and images belong to their owners. Being listed in the catalog implies no partnership or integration.
To scale
Published height next to a 175 cm person. The silhouette shows size only, not the robot’s shape.
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.