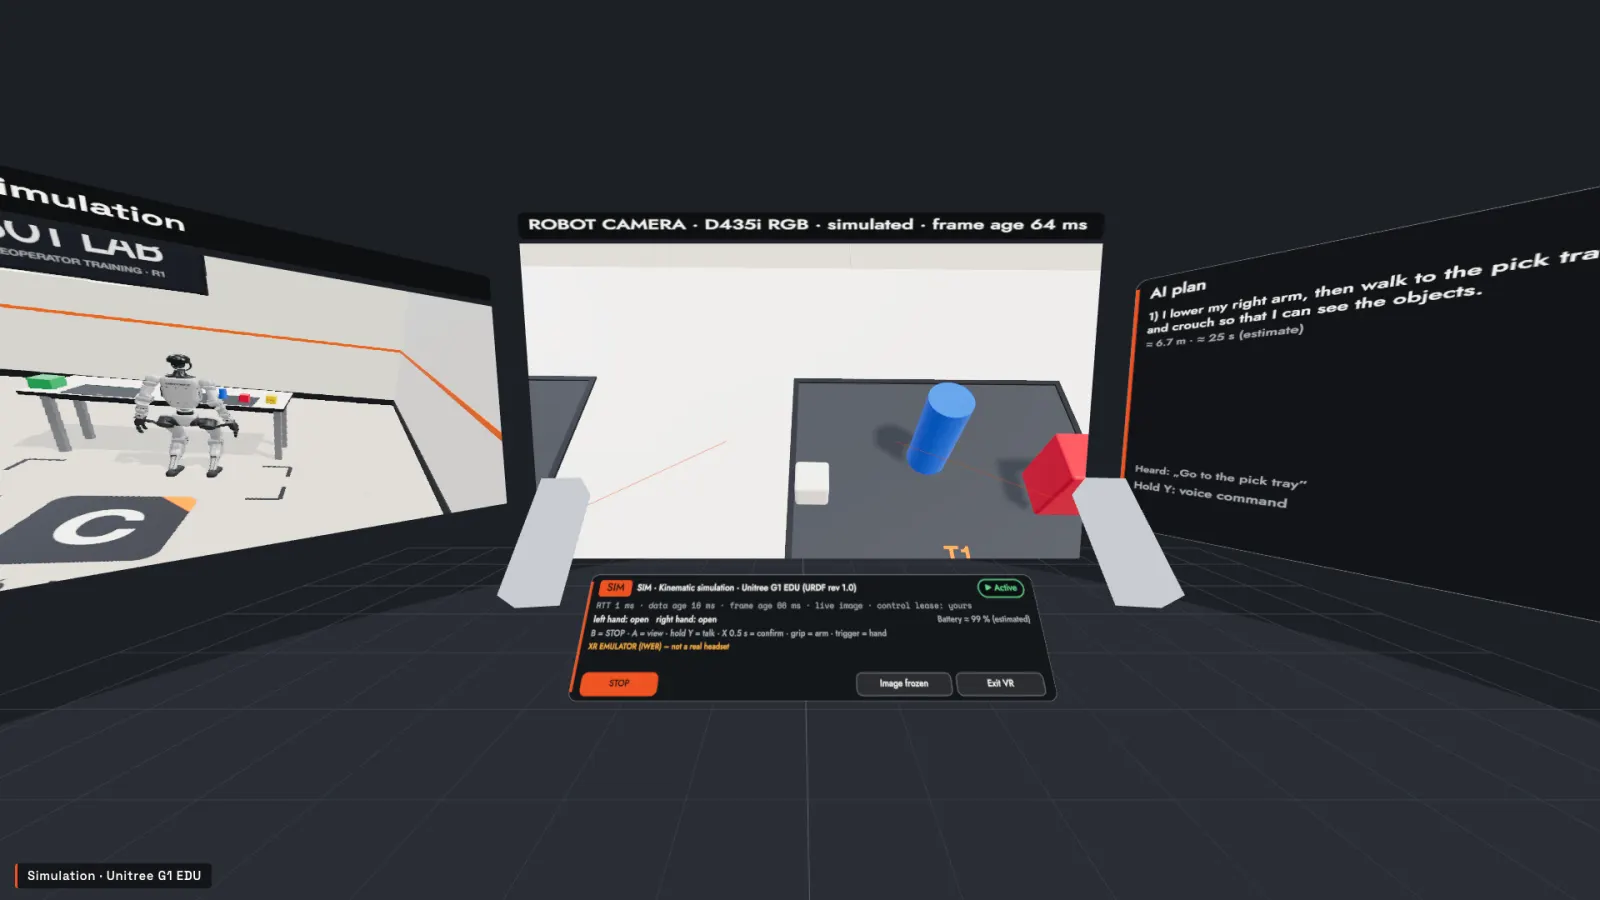
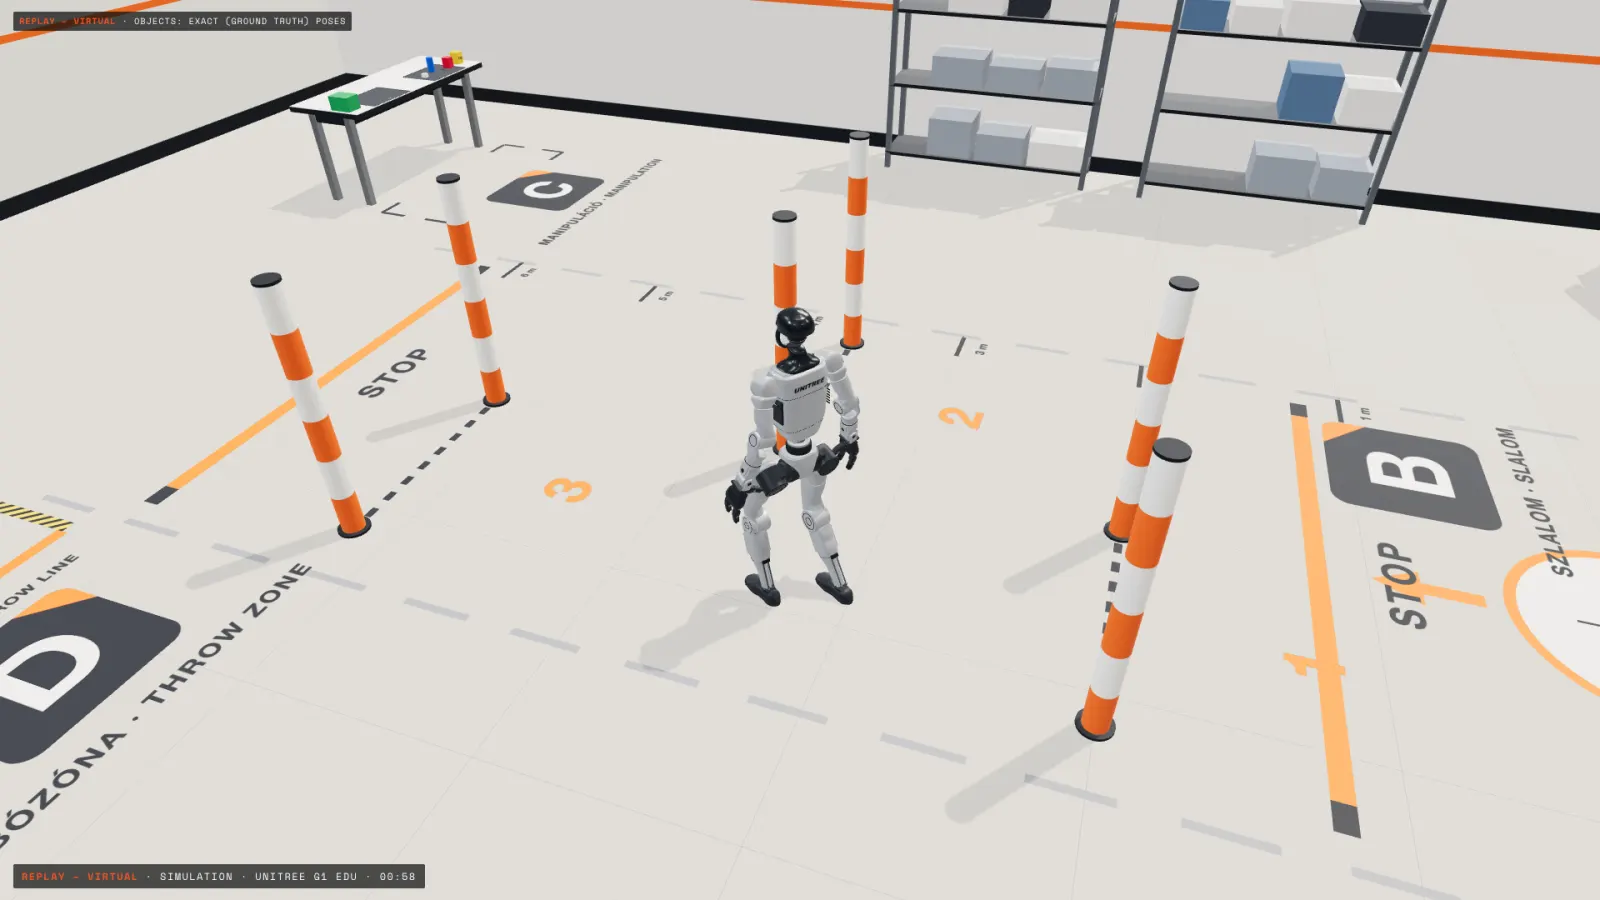
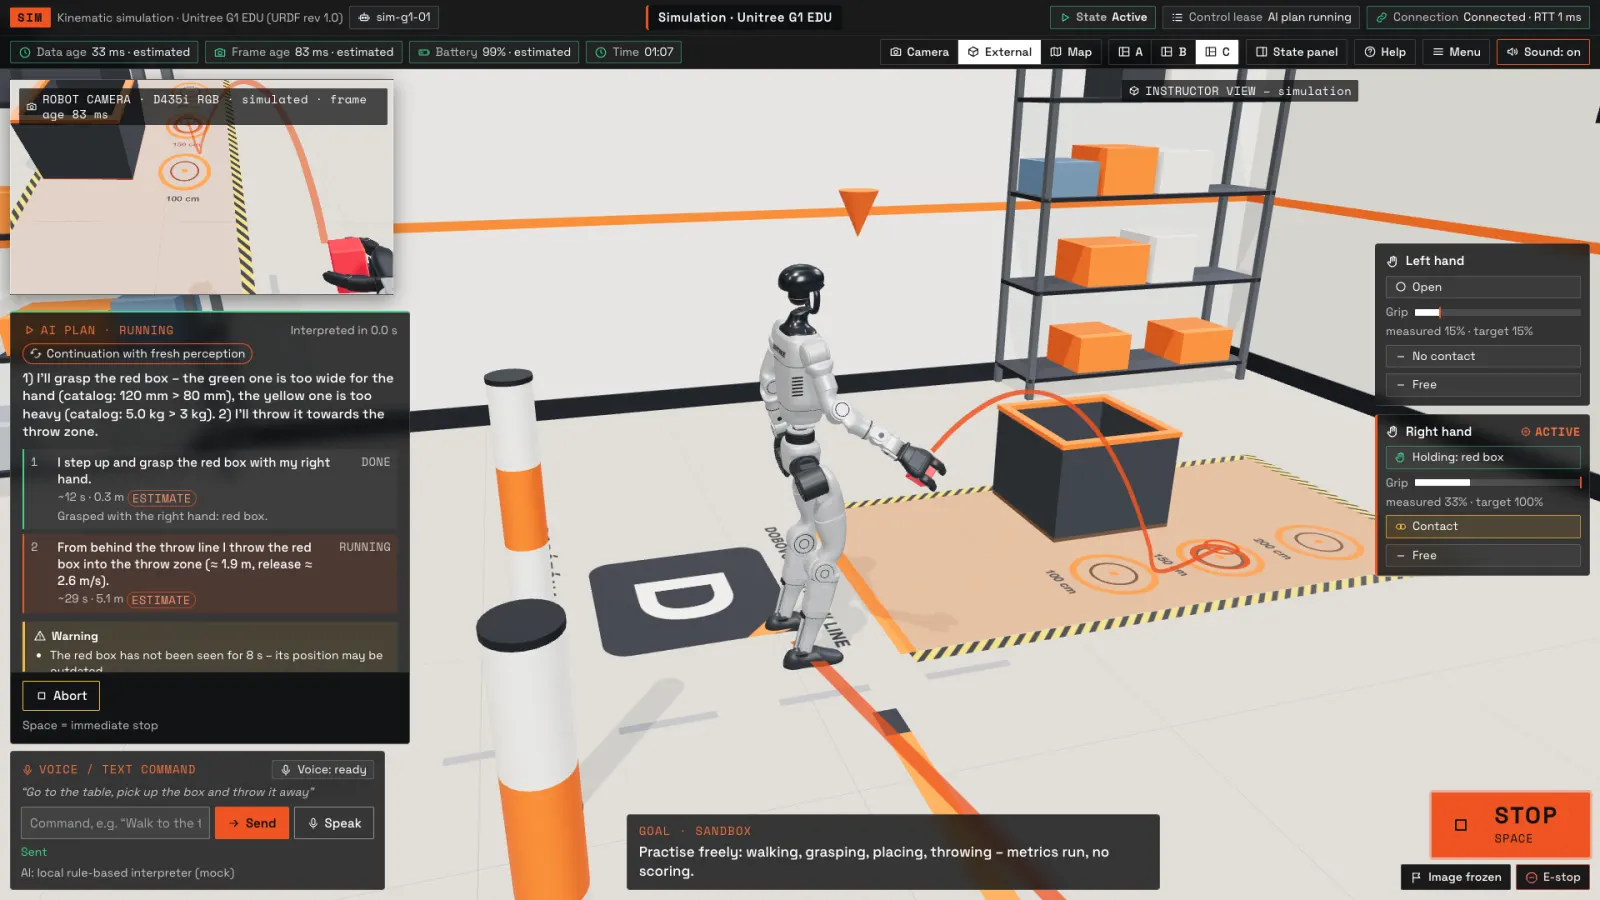
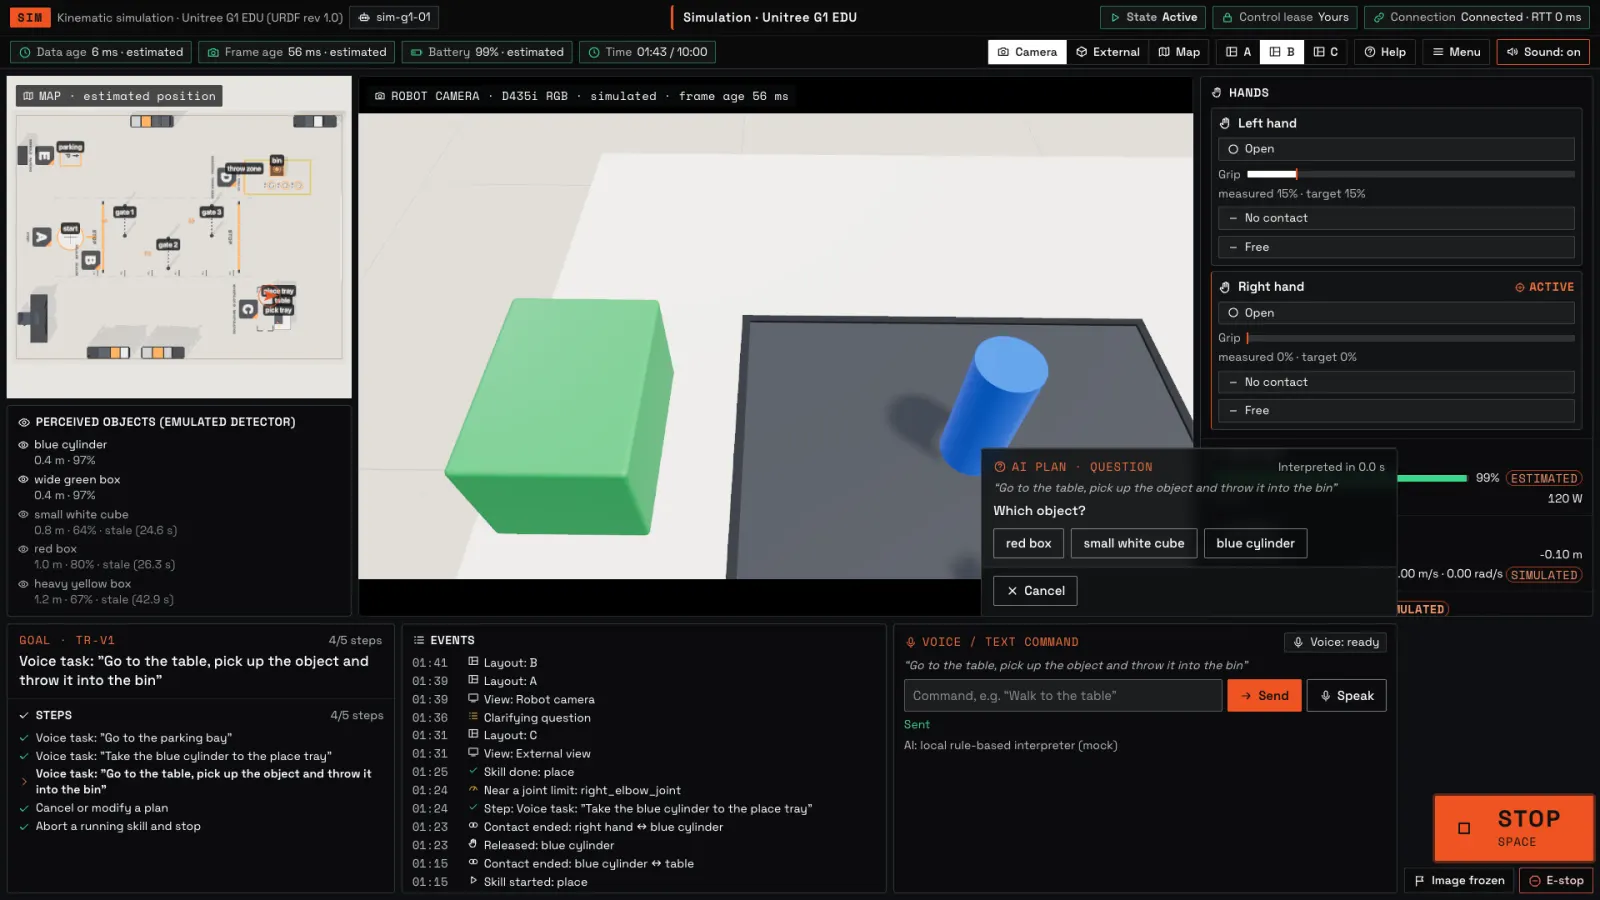
 Simulation – real application recording
Development service
Real-world teleoperation
We build operator systems for remote control of humanoid robots. The interface starts from the robot’s cameras, sensors and real capabilities.
Integrations: Unitree G1 EDU – simulated · Unitree SDK adapter – planned