
Unitree Robotics
Unitree H2
Unitree's 1.82 m, about 70 kg full-size biped humanoid with 31 DoF (including a 2-DoF head) and a wide-FOV binocular head camera; EDU version available.
Catalog dataAvailableBipedal humanoidPublic SDK
- Height
- 1.82 m
- Mass
- 70 kg
- Total DoF
- 31
- Payload
- 15 kg
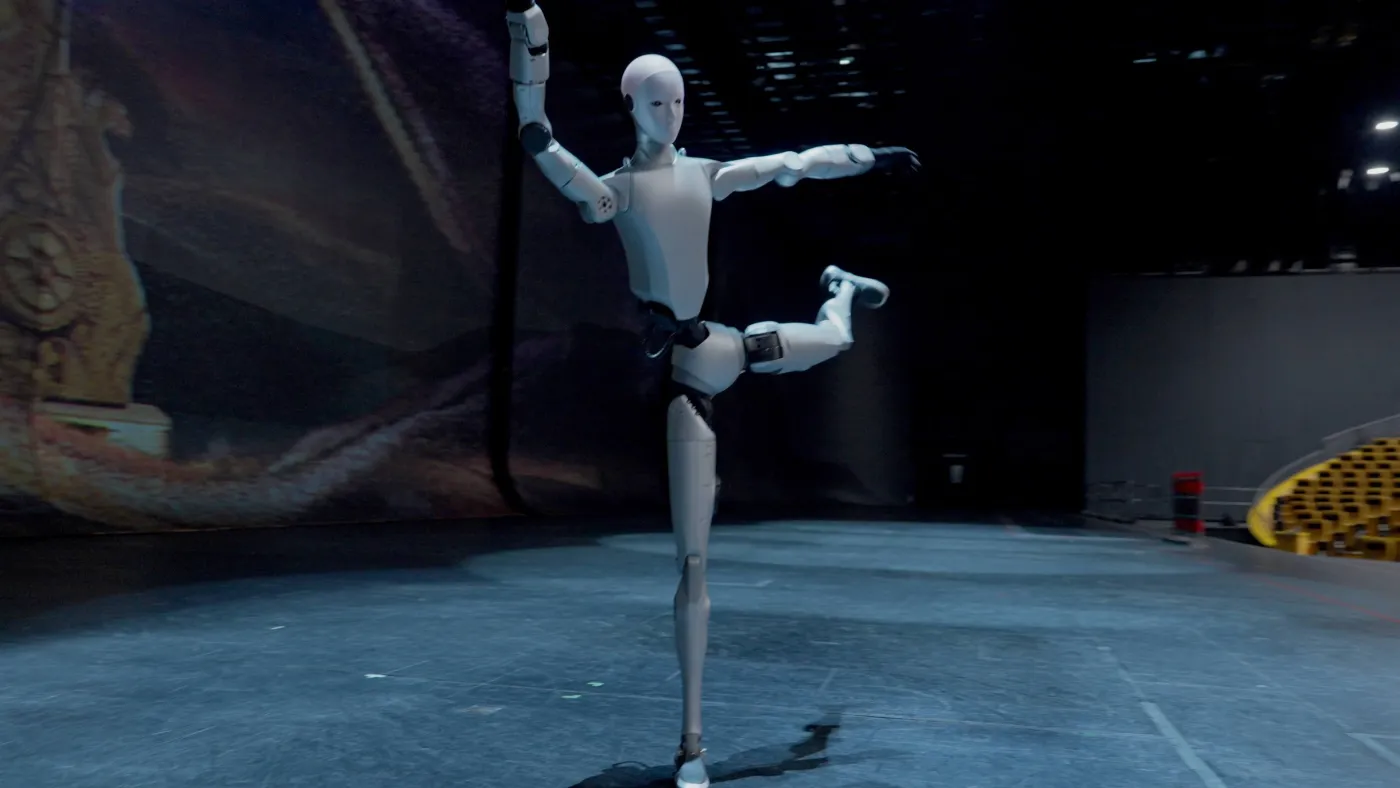 Image: © Unitree Robotics
ARworks
ARworks status by function
What works with this robot at ARworks today – and what does not.
Catalog data No ARworks integration for this robot: catalog data only. Integration follows a per-robot assessment.
Unitree H2
Technical data
From manufacturer or primary sources. The superscript points to the source.
Geometry
Kinematics
Actuators and hands
| Variant | H2base version | H2 EDUdeveloper (EDU) version |
|---|---|---|
| Drive | Low-inertia, high-speed internal-rotor PMSM joint motors; industrial crossed roller bearings; local air cooling1 | Low-inertia, high-speed internal-rotor PMSM joint motors; industrial crossed roller bearings; local air cooling1 |
| Max joint torque | 360 N·m1 | 360 N·m1 |
| Hand / gripper | Not published | Dexterous hand, multiple model options1 |
Sensing and compute
| Variant | H2base version | H2 EDUdeveloper (EDU) version |
|---|---|---|
| Vision | Humanoid wide-FOV binocular camera in the head: 2 RGB sensors, global shutter, 2064×1552 px, 30 FPS, 60 mm baseline, 156°×116° FOV2 | Humanoid wide-FOV binocular camera in the head: 2 RGB sensors, global shutter, 2064×1552 px, 30 FPS, 60 mm baseline, 156°×116° FOV2 |
| Other sensing | Array microphone and high-power speaker for voice interaction1 | Array microphone and high-power speaker for voice interaction1 |
| Onboard compute | PC1: Intel Core i5 (platform capabilities)1 | PC1: Intel Core i5 (platform capabilities) + PC2: Intel Core i7 (custom development); optional high-power module, e.g. Thor1 |
Energy and connectivity
Development
| Variant | H2base version | H2 EDUdeveloper (EDU) version |
|---|---|---|
| SDK / API | Secondary development not listed for the base model ('/')1 | Secondary development supported; H2 SDK Development Guide (SDK overview, DDS services, motion control, ROS 2 routines)2 |
| Robot description files | URDF and MJCF in unitree_ros (h2_description, 31 DoF; closed-loop ankle variant included)4 | URDF and MJCF in unitree_ros (h2_description, 31 DoF; closed-loop ankle variant included)4 |
| Simulation | MuJoCo model in the unitree_mujoco simulator (h2)5 | MuJoCo model in the unitree_mujoco simulator (h2)5 |
Size
Editorial notes
- The 2070 TOPS compute figure on the product page refers to the optional Jetson Thor unit, not the base configuration.
- Both peak and rated arm payloads are published; the table shows the peak, the rated value is in the condition.
Sources
- Unitree H2 Destiny Awakening | Unitree Robotics — Unitree Robotics · checked 2026-11-17
- About H2 – H2 SDK Development Guide (Unitree Documentation Center) — Unitree Robotics · checked 2026-11-17
- Unitree H2 – Unitree official store — Unitree Robotics · checked 2026-11-17
- unitree_ros – robots/README.md (robot descriptions) — Unitree Robotics · checked 2026-11-17
- unitree_mujoco (README, unitree_robots/h2) — Unitree Robotics · checked 2026-11-17
- xr_teleoperate – README — Unitree Robotics · checked 2026-11-17
- unitree_sdk2 – Unitree robot sdk version 2 — Unitree Robotics · checked 2026-11-17
Data sheet last checked: 2026-11-17 · China · Manufacturer names and images belong to their owners. Being listed in the catalog implies no partnership or integration.
Start a project
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.