
Fourier
Fourier GR-1
Fourier's first-generation biped humanoid (1.65 m, approx. 52 kg) with up to 44 DoF, FSA actuators and 6-DoF dexterous hands; no longer in the current product line-up.
Catalog dataDiscontinuedBipedal humanoidPublic SDK
- Height
- 1.65 m
- Mass
- 52 kg
- Total DoF
- 44
- Payload
- 3 kg
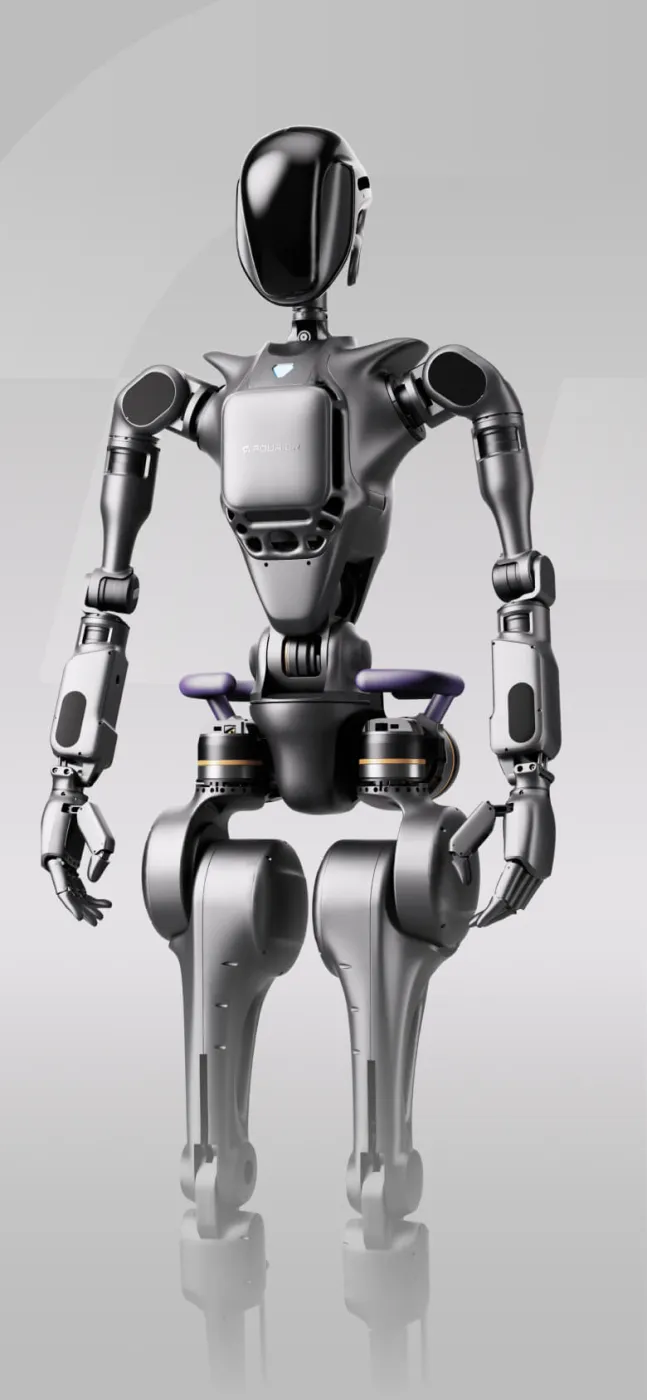 Image: © Fourier
ARworks
ARworks status by function
What works with this robot at ARworks today – and what does not.
Catalog data No ARworks integration for this robot: catalog data only. Integration follows a per-robot assessment.
Fourier GR-1
Technical data
From manufacturer or primary sources. The superscript points to the source.
Geometry
Payload and locomotion
Actuators and hands
| Drive | Fourier FSA actuators (32 FSA; total actuators 44/34), Ethernet bus, 46 V rated (12–60 V) supply; parallel mechanism at the ankle2 |
|---|---|
| Max joint torque | 230 N·m2 |
| Hand / gripper | 6-DoF dexterous hand: thumb abduction/adduction and rotation, flexion of the four fingers; controlled via Ethernet-to-RS485 conversion2 |
Sensing and compute
Energy and connectivity
Development
| SDK / API | Aurora motion-control SDK: Python client over DDS to the Aurora server; documentation on the legacy developer center3 |
|---|---|
| Robot description files | URDF models in the Wiki-GRx-Models repository (GR1T1 / GR1T2, with Fourier hand or jaw gripper)4 |
| Simulation | NVIDIA Isaac Gym (Wiki-GRx-Gym, gr1 branch); MuJoCo (Wiki-GRx-MuJoCo, gr1 branch)5 |
Size
Editorial notes
- Fourier’s current site has no GR-1 data sheet; the values come from the maker’s earlier developer docs. “Discontinued” is our inference: the model is not in the maker’s current line-up.
- The source does not label the dimension order; we took 1650 mm as the height.
Sources
- About GRx — Fourier · checked 2026-11-17
- GR-1 Introduction – Fourier Docs (legacy developer center) — Fourier · checked 2026-11-17
- GR-1 SDK Development Guide – Overview — Fourier · checked 2026-11-17
- Wiki-GRx-Models – GR1 README (name table and URDF list) — Fourier (FFTAI) · checked 2026-11-17
- Wiki-GRx-Gym (gr1 branch README) — Fourier (FFTAI) · checked 2026-11-17
- About Fourier (company timeline) — Fourier · checked 2026-11-17
- Fourier GR Family Product Catalog (2026-10) — Fourier · checked 2026-11-17
- Fourier Developer Center (current) — Fourier · checked 2026-11-17
Data sheet last checked: 2026-11-17 · China · Manufacturer names and images belong to their owners. Being listed in the catalog implies no partnership or integration.
Start a project
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.