
Fourier
Fourier N1
Fourier's open-source 1.3 m, 38 kg biped research humanoid; 23 DoF with no hand joints, built for walking, running and stair climbing in locomotion research.
Catalog dataAvailableBipedal humanoidOpen source
- Height
- 1.3 m
- Mass
- 38 kg
- Total DoF
- 23
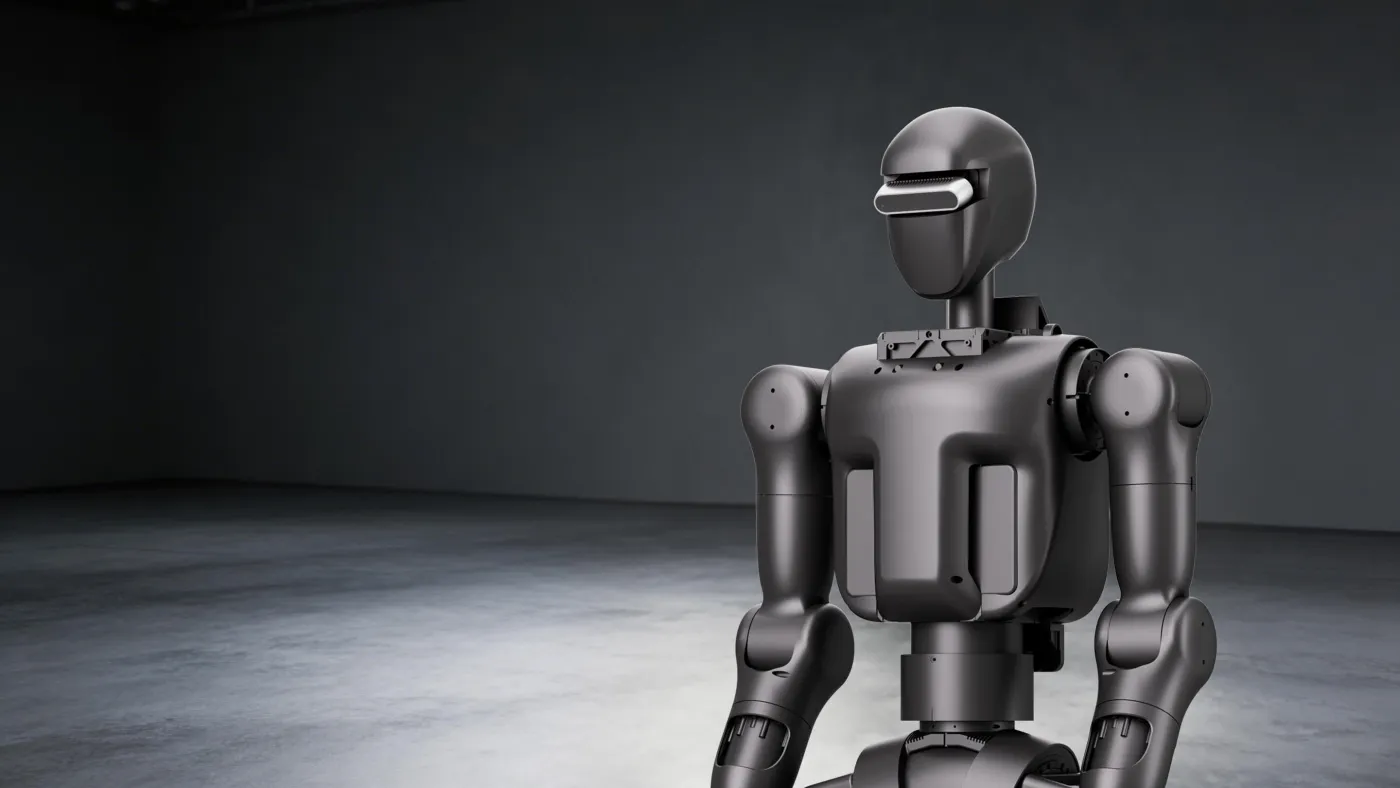 Image: © Fourier
ARworks
ARworks status by function
What works with this robot at ARworks today – and what does not.
Catalog data No ARworks integration for this robot: catalog data only. Integration follows a per-robot assessment.
Fourier N1
Technical data
From manufacturer or primary sources. The superscript points to the source.
Geometry
Payload and locomotion
Actuators and hands
Sensing and compute
Energy and connectivity
Development
| SDK / API | Fourier-GRX-N1 SDK (Python): User, Developer and PubSub interfaces, User/PubSub over Zenoh; legacy docs also reference the Aurora SDK3 |
|---|---|
| Robot description files | N1_raw.urdf and N1_rotor.urdf (Wiki-GRx-Models, FourierN1 branch); MJCF in the Wiki-GRx-MuJoCo FourierN1 branch7 |
| Simulation | RL training in Isaac Gym (Wiki-GRx-Gym, FourierN1 branch), validation in MuJoCo (Wiki-GRx-MuJoCo)6 |
| License | SDK documentation: MIT; Wiki-GRx-Models repository: GPL-3.0; hardware package (Baidu Netdisk) license not stated9 |
Size
Editorial notes
- The maker’s own sources disagree (height 130 cm vs 1245 mm; mass 38 vs about 39 kg; top speed and torque). The table shows the product-page values.
- No hands: each arm ends in a wrist yaw joint.
Sources
- Fourier N1 — Fourier · checked 2026-11-17
- Fourier N1 Introduction – Fourier Docs (legacy developer center) — Fourier · checked 2026-11-17
- Fourier-GRX-N1 SDK 开发文档 (index) — Fourier (FFTAI) · checked 2026-11-17
- N1 机器人 – 快速开始 (Fourier-GRX-N1 docs) — Fourier (FFTAI) · checked 2026-11-17
- 机器人关节序列 (Fourier-GRX-N1 docs) — Fourier (FFTAI) · checked 2026-11-17
- N1 机器人 – 模型训练 (Fourier-GRX-N1 docs) — Fourier (FFTAI) · checked 2026-11-17
- Wiki-GRx-Models, FourierN1 branch (README, N1 URDF) — Fourier (FFTAI) · checked 2026-11-17
- About Fourier (company timeline) — Fourier · checked 2026-11-17
- fourier-grx-N1 LICENSE — Fourier (FFTAI) · checked 2026-11-17
- Fourier GR Family Product Catalog (2026-10) — Fourier · checked 2026-11-17
Data sheet last checked: 2026-11-17 · China · Manufacturer names and images belong to their owners. Being listed in the catalog implies no partnership or integration.
Start a project
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.