
Unitree G1
Unitree's 1.32 m, about 35 kg biped humanoid. Base G1 has 23 DoF; G1 EDU has 23–43 DoF, optional Dex3-1 hands and a Jetson Orin development unit.
- Height
- 1.32 m
- Mass
- 35 kg
- Total DoF
- 23
- Payload
- 2 kg
The VR operator training runs with this robot (simulation) →
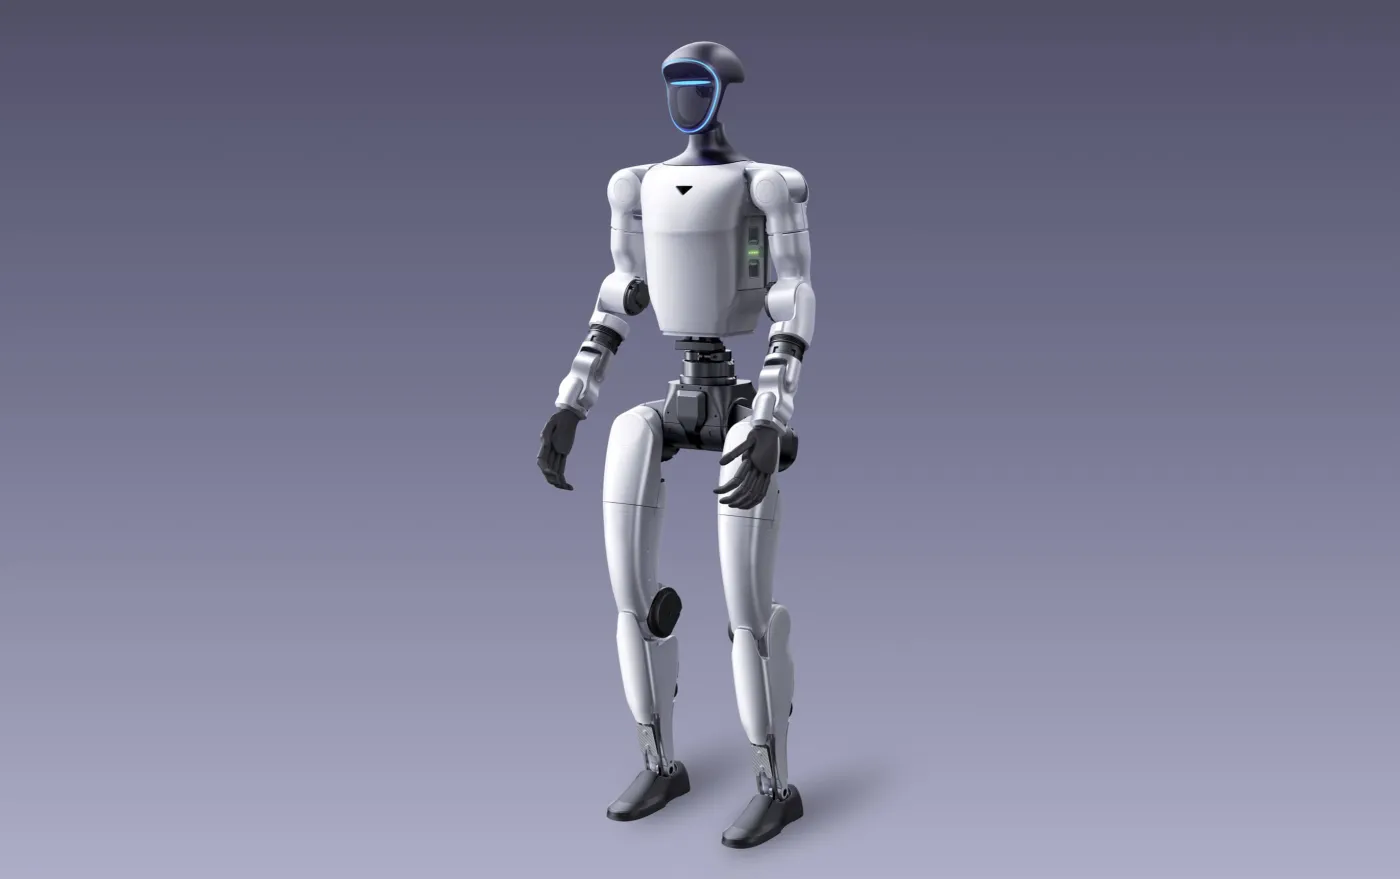 Image: © Unitree Robotics
ARworks status by function
What works with this robot at ARworks today – and what does not.
- Kinematic modelSimulated
R1 training: URDF-accurate geometry, joint limits, speed limits, self- and environment collision; main dimensions within 1% of factory values. No dynamics (balance, falls, forces).
Variant: G1 EDU · 2026-11-17 - 3D model3D model
Code-built, fully articulated model using the official URDF kinematics – our own work, not a vendor mesh. No 3D viewer on the website yet.
Variant: G1 EDU · 2026-11-17 - Walking (velocity request)Simulated
Emulated gait within the walking limits. Known deviation: at start-up the leg joint speed can exceed the URDF limit (measured 39.7 rad/s vs 20 rad/s).
Variant: G1 EDU · 2026-11-17 - Arm control (IK)Simulated
Mouse and keyboard on a laptop, clutch in VR. An unreachable target causes no jump or joint-limit violation (tested). VR verified only in the IWER emulator.
Variant: G1 EDU · 2026-11-17 - Hand and grasp (Dex3, single hand)Simulated
Geometric grasp without force simulation, within the training profile limits (80 mm hand opening, 3 kg per arm). No bimanual grasp – planned (R2).
Variant: G1 EDU · 2026-11-17 - Head camera (D435i)Simulated
Client-side render following the camera profile: 69° × 42° field of view, 47.6° downward tilt. The image is not a real camera stream.
Variant: G1 EDU · 2026-11-17 - Fault handling (latency, freeze, dropout)Simulated
Simulated network profiles and one-off events; stale late commands are discarded by the core, a frozen image is clearly flagged (tested).
Variant: G1 EDU · 2026-11-17 - Unitree SDK adapterPlanned
R4: the command mapping to the unitree_sdk2 G1 interface exists as a plan (locomotion, arm, Dex3, state); to be verified on firmware and SDK version.
Variant: G1 EDU · 2026-11-17 - Test on a real robotPlanned
Not done yet. It needs the robot, firmware, peripherals, on-site supervision and a per-robot acceptance test.
Variant: G1 EDU · 2026-11-17
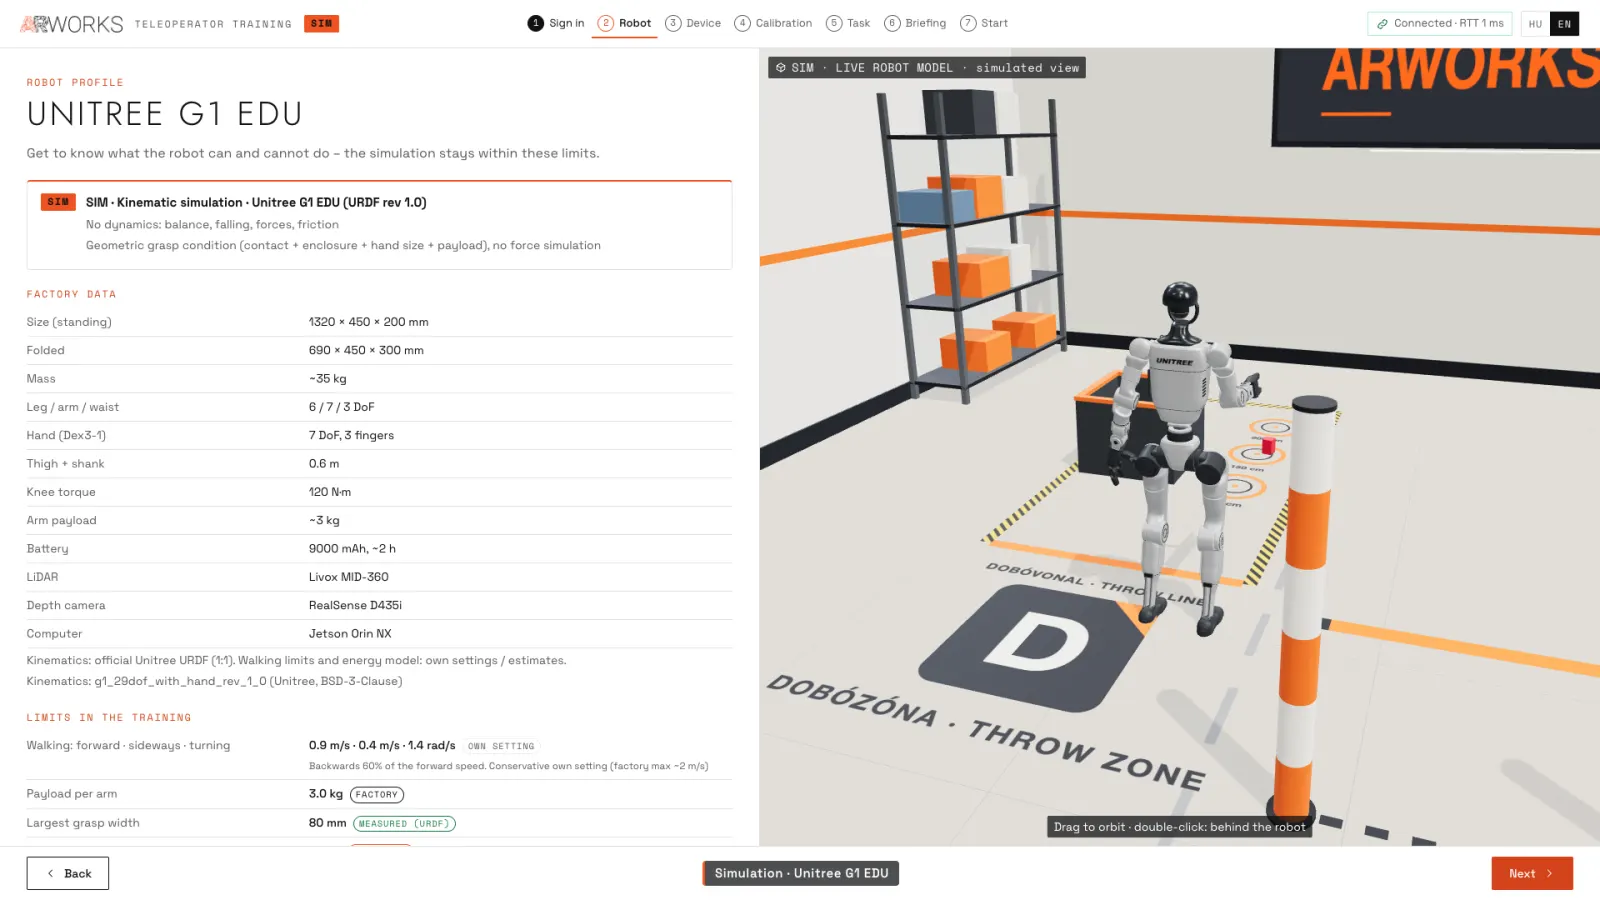 Simulation – real application recording
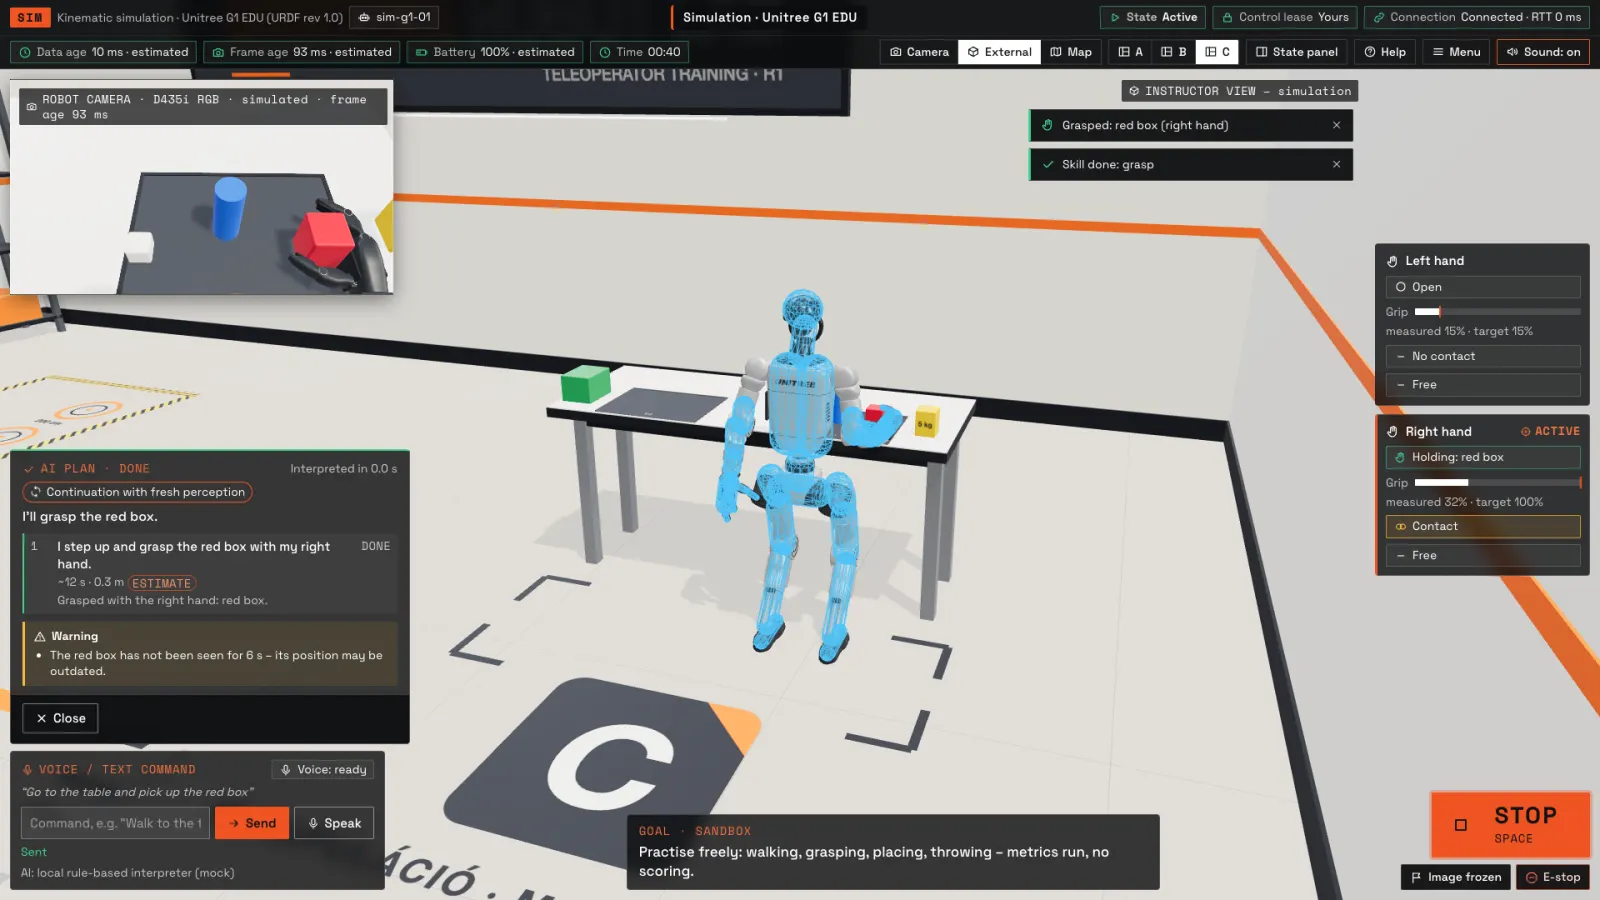 Simulation – real application recording
Technical data
From manufacturer or primary sources. The superscript points to the source.
Geometry
Kinematics
Payload and locomotion
Actuators and hands
| Variant | G1base version | G1 EDUdeveloper (EDU) version; sub-versions see notes |
|---|---|---|
| Drive | Low-inertia, high-speed internal-rotor PMSM joint motors; industrial crossed roller bearings; dual encoders; hollow internal wiring; local air cooling1 | Low-inertia, high-speed internal-rotor PMSM joint motors; industrial crossed roller bearings; dual encoders; hollow internal wiring; local air cooling1 |
| Max joint torque | 90 N·m1 | 120 N·m1 |
| Hand / gripper | Not published | Optional Dex3-1 force-controlled three-finger hand (thumb 3, index 2, middle 2 active DoF), optional tactile sensor arrays1 |
Sensing and compute
| Variant | G1base version | G1 EDUdeveloper (EDU) version; sub-versions see notes |
|---|---|---|
| Vision | D435i depth camera in the head2 | D435i depth camera in the head2 |
| Other sensing | LIVOX MID-360 3D LiDAR in the head (360° horizontal, up to 59° vertical FOV); 4-microphone array; 5 W speaker2 | LIVOX MID-360 3D LiDAR in the head (360° horizontal, up to 59° vertical FOV); 4-microphone array; 5 W speaker2 |
| Onboard compute | 8-core high-performance CPU1 | 8-core CPU (motion-control unit, closed to users) + development computing unit (PC2): NVIDIA Jetson Orin NX, 16 GB memory, 2 TB storage2 |
Energy and connectivity
Development
| Variant | G1base version | G1 EDUdeveloper (EDU) version; sub-versions see notes |
|---|---|---|
| SDK / API | Secondary development not listed for the base model ('/')1 | Secondary development supported: unitree_sdk2 (C++) with the G1 SDK Development Guide3 |
| Robot description files | URDF and MJCF in unitree_ros (g1_description: 23- and 29-DoF, with-hand and other variants)4 | URDF and MJCF in unitree_ros (g1_description: 23- and 29-DoF, with-hand and other variants)4 |
| Simulation | MuJoCo models in the unitree_mujoco simulator (g1_23dof, g1_29dof)5 | MuJoCo models in the unitree_mujoco simulator (g1_23dof, g1_29dof)5 |
- For the arm payload (about 2 kg / about 3 kg) the maker does not say whether it is per arm or in total; the value depends strongly on the arm posture.
- The G1 EDU sub-versions (Standard 23, Advanced 29, Ultimate A–D 29 DoF + Dex3-1 or Inspire hands) differ only in DoF and hands; the maker publishes no separate specifications.
- The current product page publishes no walking speed.
- Humanoid robot G1_Humanoid Robot Functions_Humanoid Robot Price | Unitree Robotics — Unitree Robotics · checked 2026-11-17
- About G1 – G1 SDK Development Guide (Unitree Documentation Center) — Unitree Robotics · checked 2026-11-17
- Get SDK – G1 SDK Development Guide (Unitree Documentation Center) — Unitree Robotics · checked 2026-11-17
- unitree_ros – robots/README.md (robot descriptions) — Unitree Robotics · checked 2026-11-17
- unitree_mujoco (README, unitree_robots/g1) — Unitree Robotics · checked 2026-11-17
- xr_teleoperate – README — Unitree Robotics · checked 2026-11-17
- unitree_sdk2 – Unitree robot sdk version 2 — Unitree Robotics · checked 2026-11-17
- Unitree G1 – Unitree official store — Unitree Robotics · checked 2026-11-17
- unitree_rl_gym – README — Unitree Robotics · checked 2026-11-17
- unitree_rl_lab – README — Unitree Robotics · checked 2026-11-17
Data sheet last checked: 2026-11-17 · China · Manufacturer names and images belong to their owners. Being listed in the catalog implies no partnership or integration.
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.