
Pollen Robotics
Pollen Reachy 2
Open-source bimanual humanoid upper body on an omnidirectional mobile base from Pollen Robotics (Hugging Face): 7-DoF arms, Python SDK, ROS 2 Humble, VR teleoperation.
Catalog dataAvailableWheeled base, humanoid upper bodyOpen source
- Height
- 1.36–1.66 m
- Mass
- 50 kg
- Payload
- 3 kg
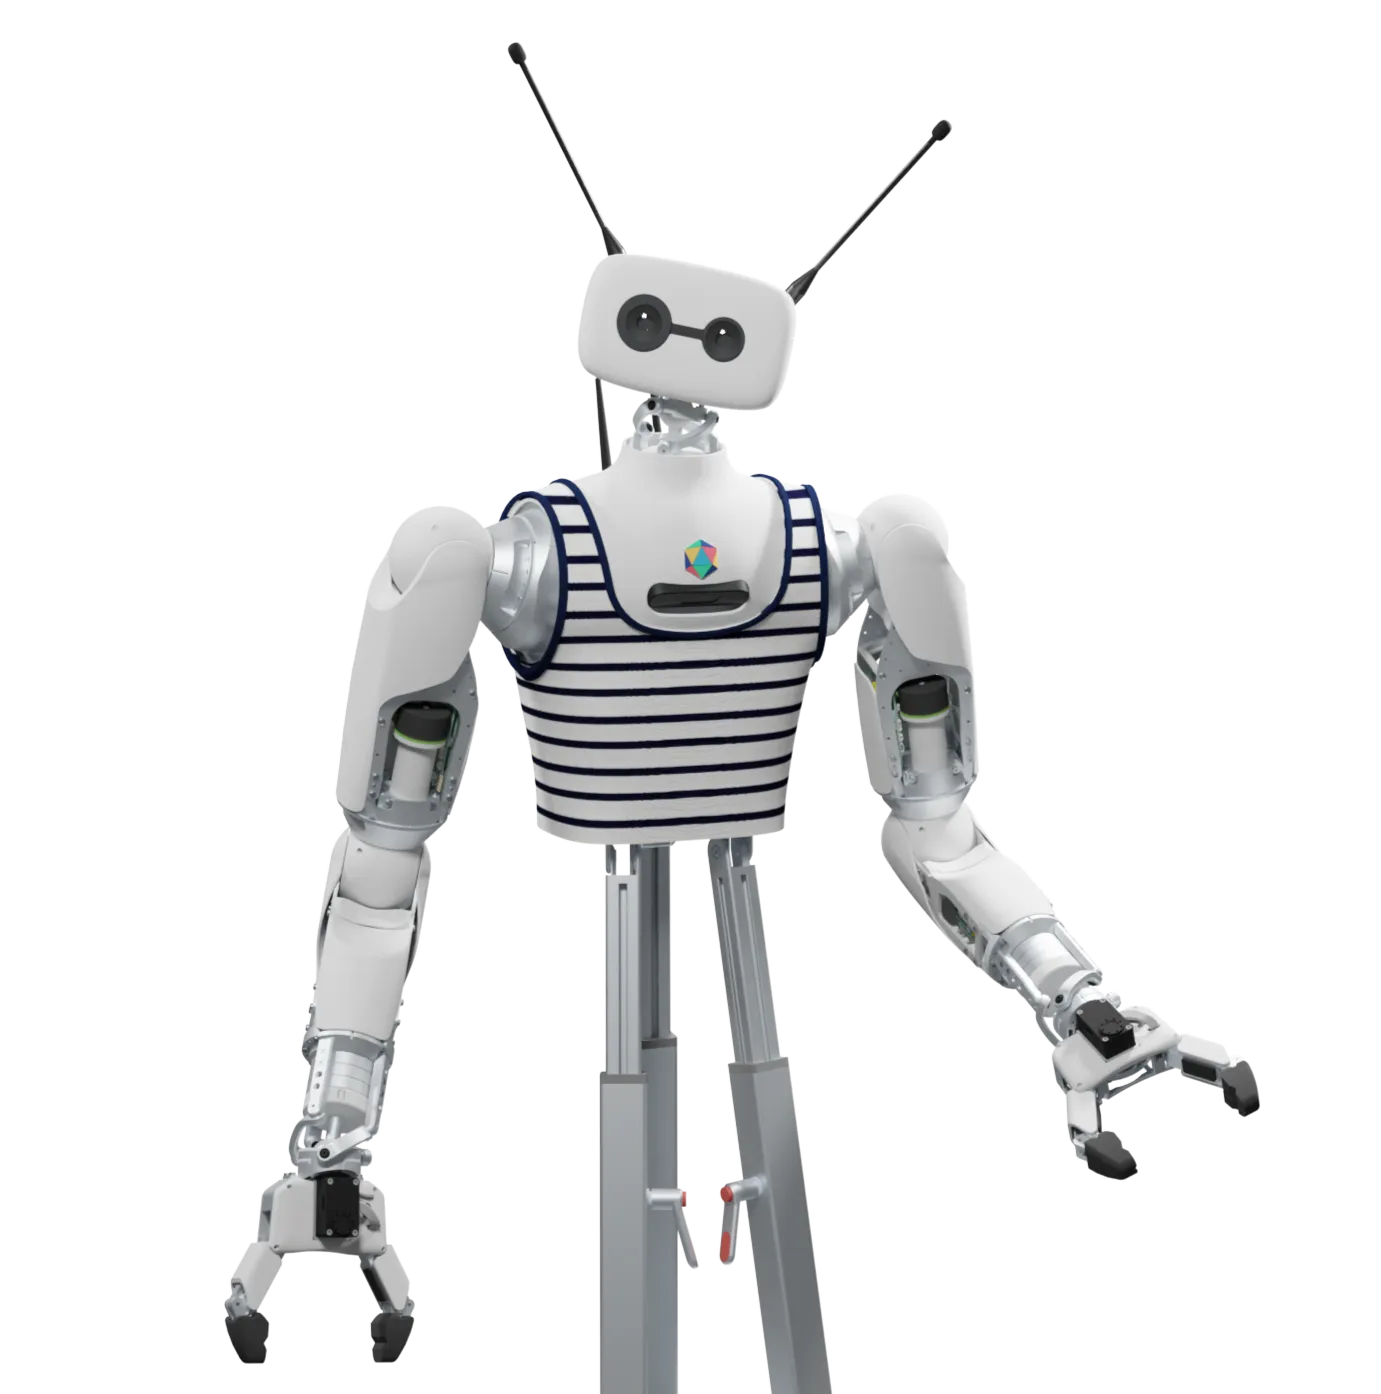 Image: © Pollen Robotics
ARworks
ARworks status by function
What works with this robot at ARworks today – and what does not.
Catalog data No ARworks integration for this robot: catalog data only. Integration follows a per-robot assessment.
Pollen Reachy 2
Technical data
From manufacturer or primary sources. The superscript points to the source.
Geometry
Kinematics
| DoF per arm | 72 |
|---|
Payload and locomotion
Actuators and hands
Sensing and compute
| Vision | head: fisheye RGB cameras (stereo view for VR teleoperation) and a ToF depth module between the eyes; torso: fixed RGB-D camera (Orbbec)3 |
|---|---|
| Other sensing | cameras, microphones, LiDAR, IMUs9 |
| Onboard compute | Solidrun Bedrock v3000 fanless industrial PC, CPU only; AI processing on the customer's own computers at this stage2 |
Development
| SDK / API | Reachy 2 Python SDK (reachy2-sdk), ROS 2 Humble interface, VR teleoperation app (Reachy2Teleoperation)1 |
|---|---|
| Robot description files | URDF/xacro robot description in the reachy2_core repository (reachy_description/urdf)10 |
| Simulation | Gazebo and MuJoCo (MuJoCo still work in progress) via a preconfigured Docker image; Python SDK and ROS 2 interface work; not available: camera access (coming soon), WebRTC, hence no teleoperation8 |
| License | Apache 2.0 (open source)1 |
Size
Editorial notes
- Height is 136–166 cm per the product page; a figure in the docs shows 1.43–1.63 m.
- Per the official docs, the camera and WebRTC teleoperation are not yet available in simulation.
- The images show the upper body without the mobile base.
Sources
- Reachy 2: open-source humanoid robot for embodied AI — Pollen Robotics · checked 2026-11-17
- Reachy 2 Specifications: Key Features, Architecture & Dimensions — Pollen Robotics · checked 2026-11-17
- Reachy 2 Vision Module: Head & Torso Camera Specifications — Pollen Robotics · checked 2026-11-17
- Motors & Actuators specifications | Reachy 2 — Pollen Robotics · checked 2026-11-17
- Grippers specifications | Reachy 2 — Pollen Robotics · checked 2026-11-17
- Mobile base specifications | Reachy 2 — Pollen Robotics · checked 2026-11-17
- Contact Pollen Robotics | Pollen Robotics — Pollen Robotics · checked 2026-11-17
- How to Run Reachy 2 Simulation with Docker: Step-by-Step Setup Guide — Pollen Robotics · checked 2026-11-17
- Reachy 2 – A Versatile Humanoid Robot for Interaction, AI & Research — Pollen Robotics · checked 2026-11-17
- pollen-robotics/reachy2_core (Reachy V2 workspace) — Pollen Robotics · checked 2026-11-17
- Reachy 2 Documentation | Reachy 2 — Pollen Robotics · checked 2026-11-17
Data sheet last checked: 2026-11-17 · France · Manufacturer names and images belong to their owners. Being listed in the catalog implies no partnership or integration.
Start a project
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.