
Balance and Locomotion
Walking needs the whole body in coordination. Balance is kept by the robot’s own local controller – not by the operator.
How it works
The local controller works from posture, joint state and ground contact. Whole-body control coordinates several body parts at once.
Running, jumping, kneeling or standing up are separate skills, with preconditions, state and abort rules. A move seen on video proves no accessible API.
What it means for teleoperation
The operator sends a velocity request (forward, sideways, turn); the robot computes the steps. Over the internet the critical control loop cannot wait for remote replies.
Example from the training
On the lab’s slalom gates and stop lines the trainee sends velocity requests; the G1 cannot jump, so a “jump over” command is refused and a detour is offered.
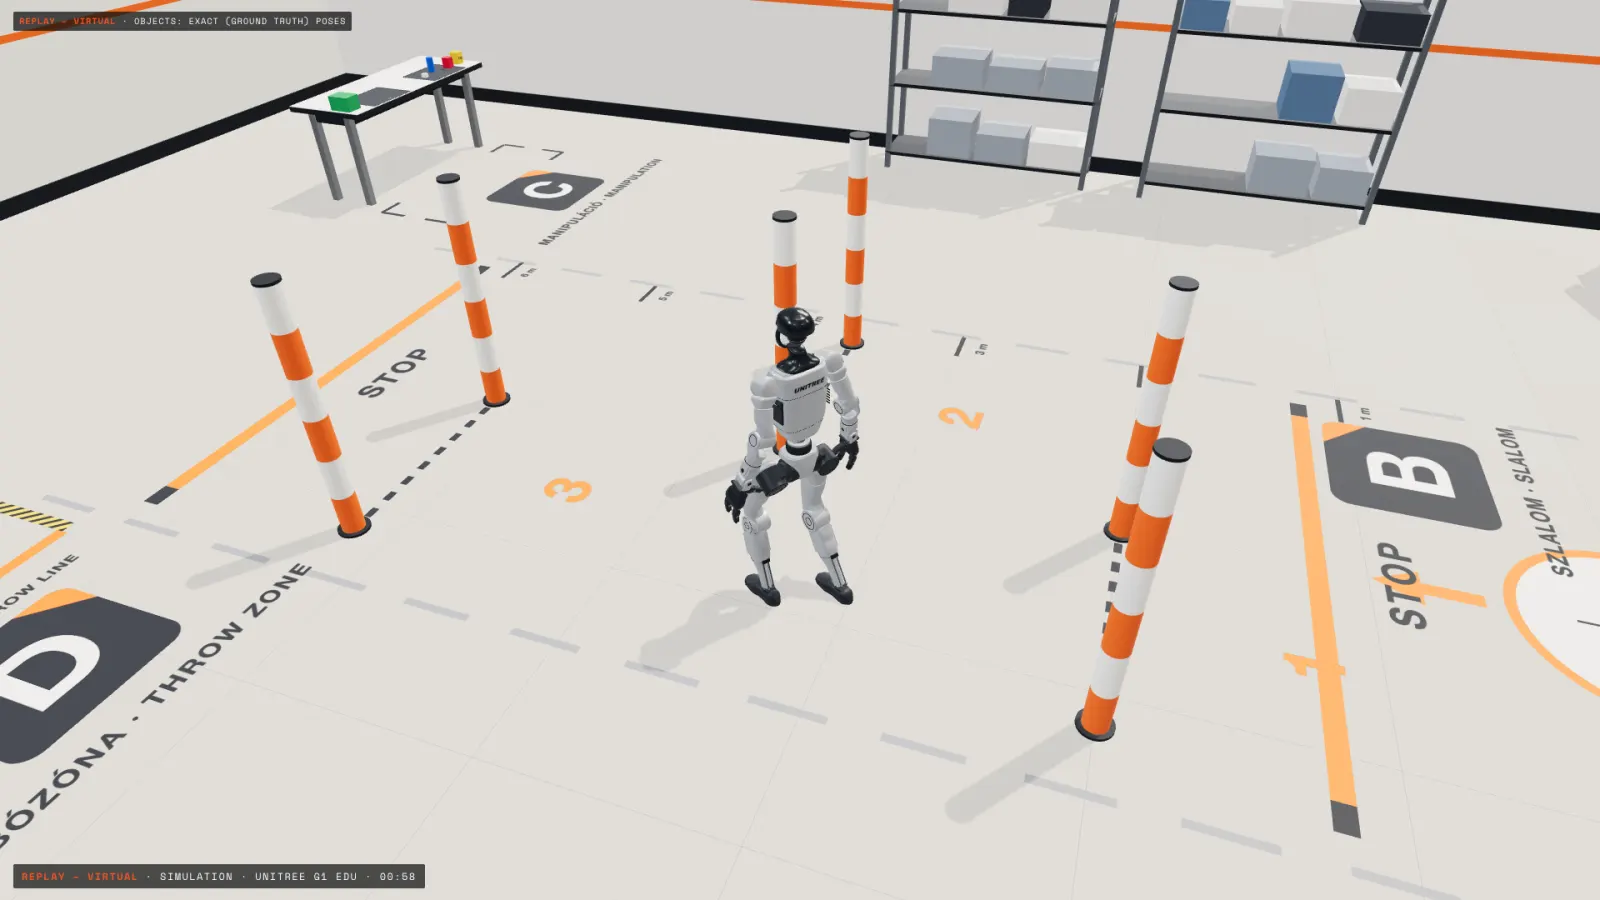 Simulation – real application recording
- OpenLoong Dynamics Control (MPC/WBC) — checked 2026-11-13
- Unitree unitree_mujoco — checked 2026-11-13
- ARworks R1 teleoperator training – README, test report, protocol (2026-11-17) — internal documentation, not public
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.