
Robot Technology Explained
Proprioception and Sensing
Proprioception is sensing the robot’s own state: joint position, velocity, motor state, IMU. Cameras and other sensors perceive the surroundings.
How it works
Perception: cameras, depth sensors, LiDAR, microphones. Touch and force sensing help judge grasps and contact.
What it means for teleoperation
On the interface measured, estimated and missing data are labeled differently. The operator knows what to rely on and what is only an estimate.
Example from the training
Example from the training
Profile B’s perceived objects come from an emulated detector, with confidence and a “stale” flag; battery and position are “estimated”.
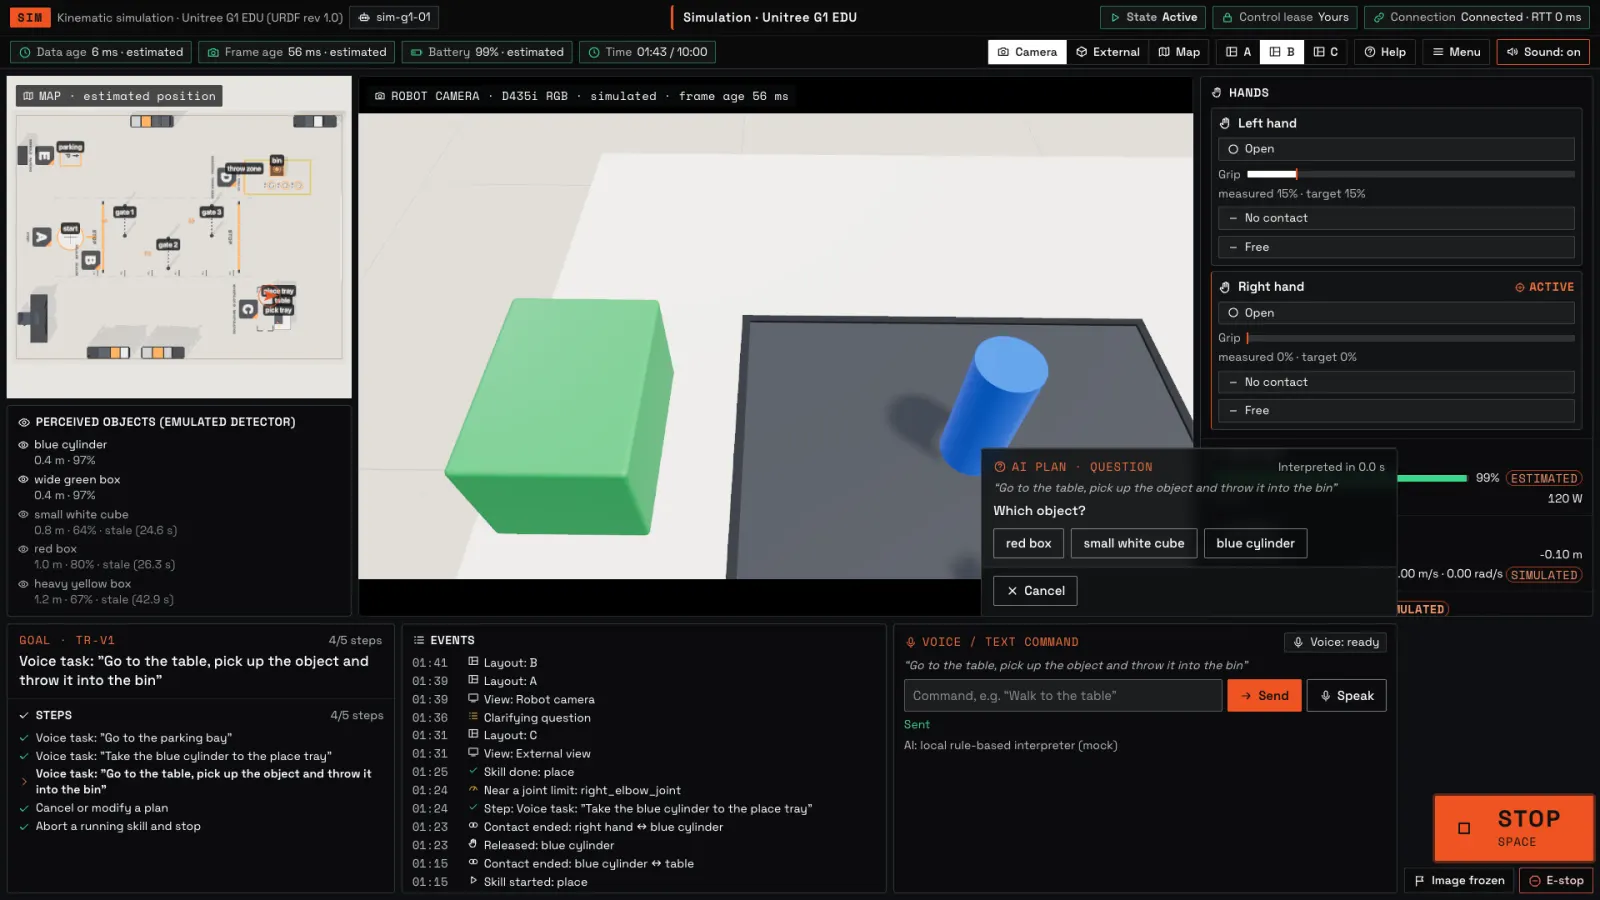 Simulation – real application recording
Sources
- Unitree unitree_sdk2 — checked 2026-11-13
- Reachy 2 – simulation documentation — checked 2026-11-13
- ARworks R1 teleoperator training – README, test report, protocol (2026-11-17) — internal documentation, not public
Start a project
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.