
Robot Technology Explained
Energy and Heat
Runtime comes from battery capacity and load-dependent consumption together. Heat can limit drive performance.
How it works
A maker’s runtime always refers to a test condition. The data sheets state it with the condition, or “Not published” when unknown.
What it means for teleoperation
The interface should show the reserve, the planned return and any power derating – with a labeled estimate when the robot data is unknown.
Example from the training
Example from the training
The training’s battery model is an estimate and is labeled “estimated”. In the fault module the battery runs low while the task must be finished.
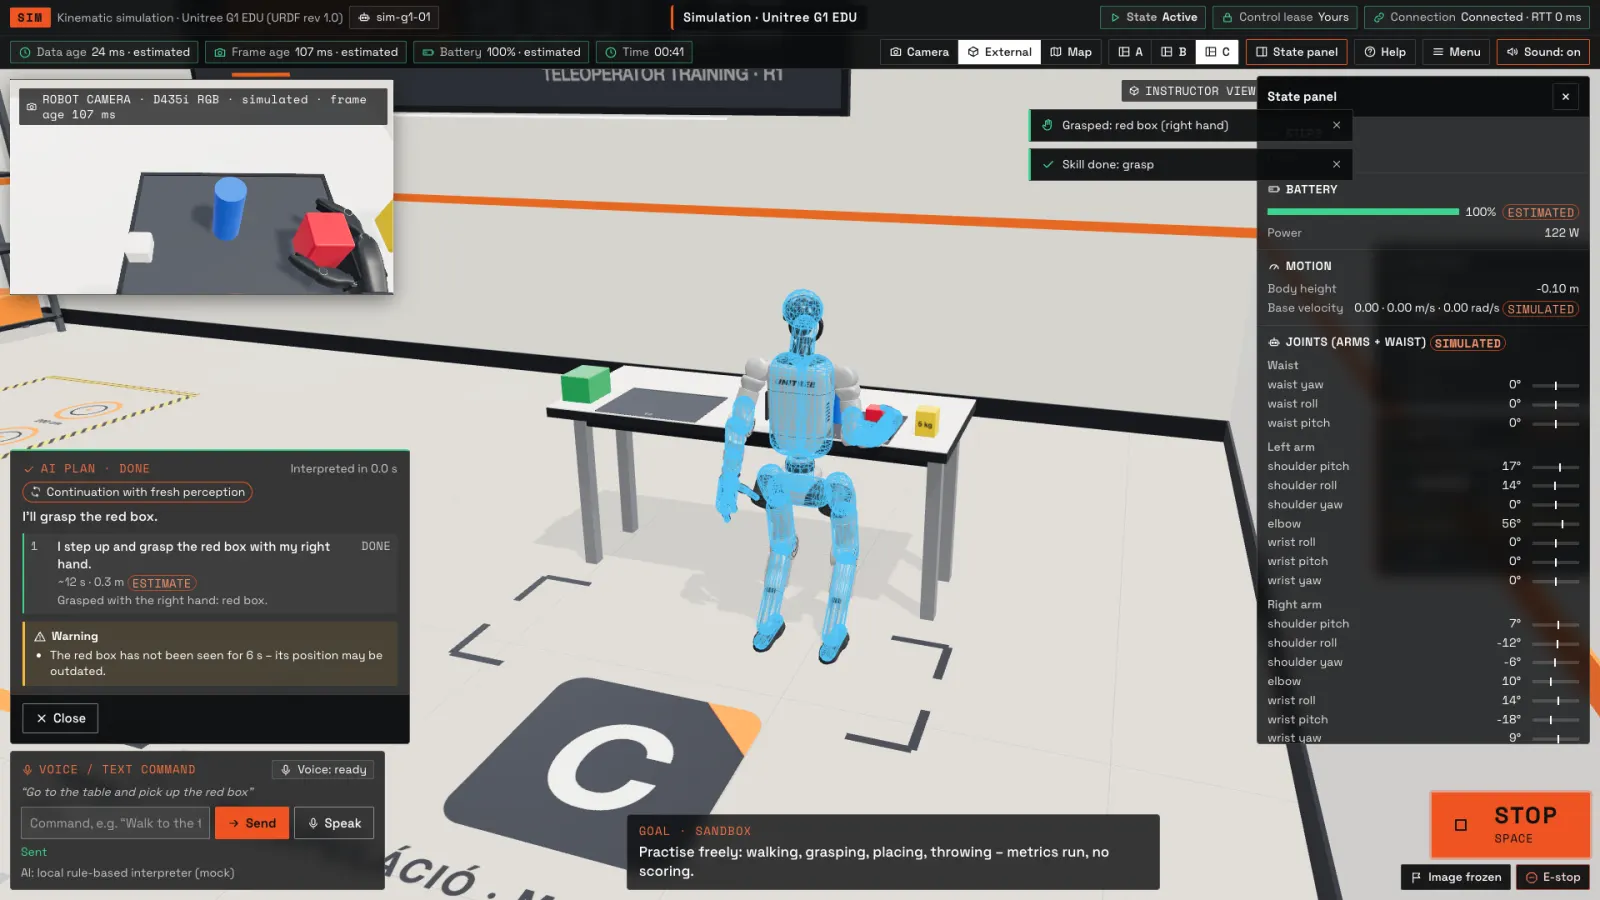 Simulation – real application recording
Sources
- Unitree G1 – manufacturer page — checked 2026-11-13
- ARworks R1 teleoperator training – README, test report, protocol (2026-11-17) — internal documentation, not public
Start a project
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.