
Robot Technology Explained
Connectivity and Telepresence
The operator-to-robot network and the robot’s internal bus are different things. The external link can be Wi-Fi, cellular or wired.
How it works
Besides latency, jitter, packet loss, bandwidth and data freshness matter too. A snagged cable and its motion limit are a practice case of their own.
What it means for teleoperation
On a network fault a locally validated, robot-specific procedure takes over. The interface shows the source, the data age and the link state.
Example from the training
Example from the training
In the fault module latency rises from 150 to 600 ms, the image freezes for 2 seconds and the command channel drops. Late, stale commands are discarded by the core.
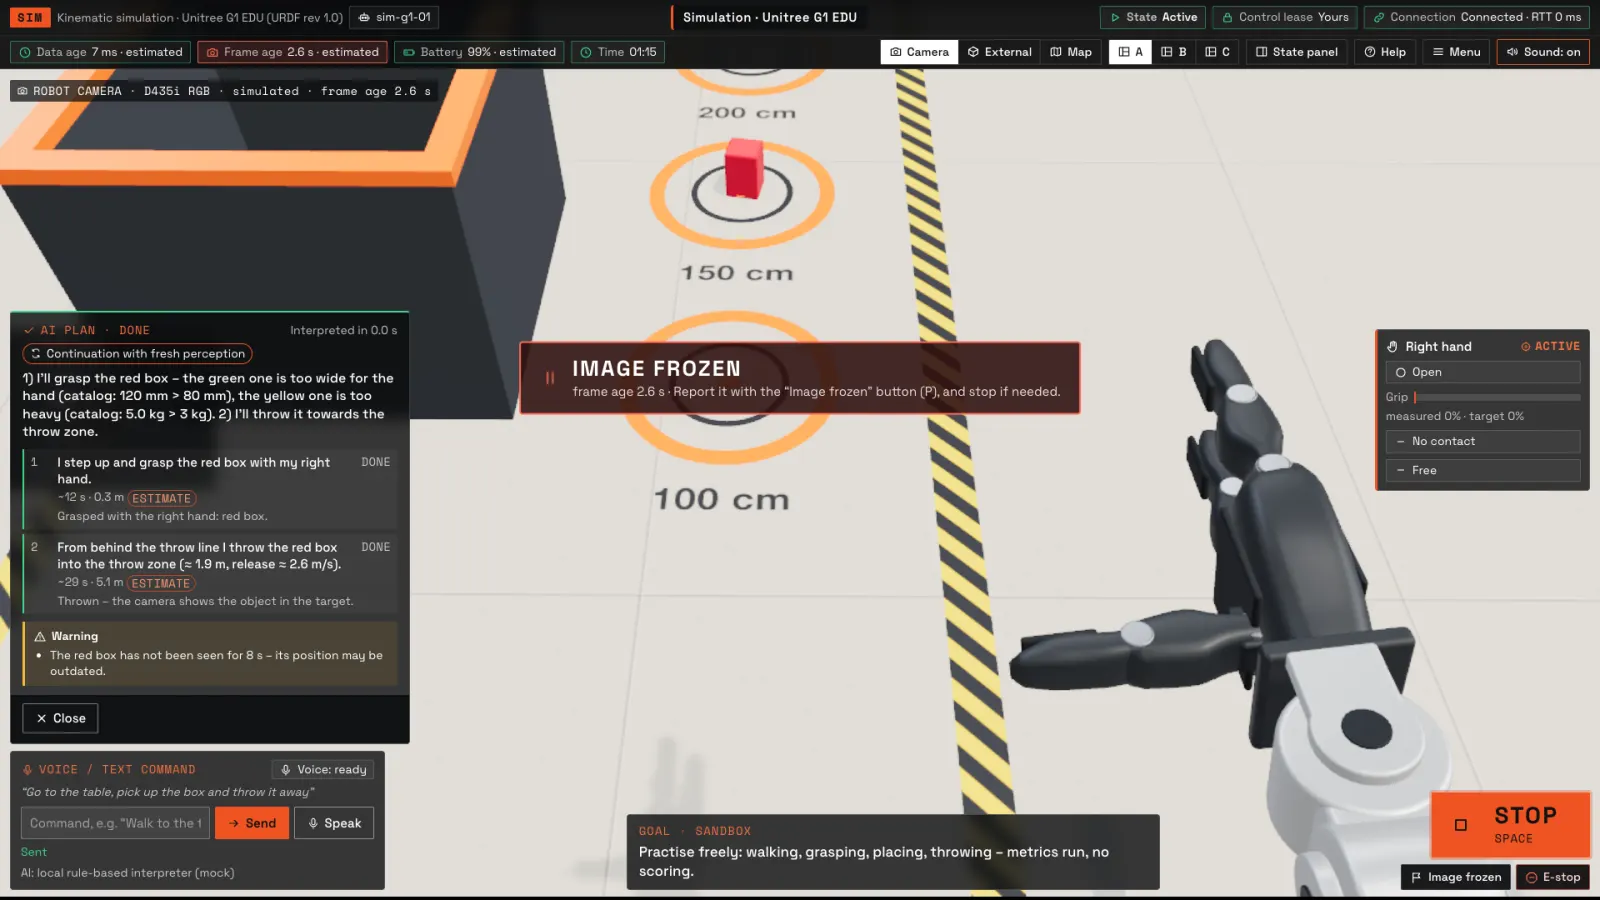 Simulation – real application recording
Sources
- Unitree xr_teleoperate — checked 2026-11-13
- Unitree unitree_sdk2 — checked 2026-11-13
- ARworks R1 teleoperator training – README, test report, protocol (2026-11-17) — internal documentation, not public
Start a project
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.