
Robot Technology Explained
Onboard Computing and AI
The onboard computer estimates state, processes sensor data and executes locally. AI can help – supervision stays human.
How it works
A learned locomotion controller does not make the robot autonomous in its task. A “pick this up” command is partial autonomy and needs a separately verified skill.
What it means for teleoperation
Suggestion and execution are clearly separated. The AI never sends motor commands; it can only request approved, parameter-limited skills.
Example from the training
Example from the training
A voice or text command becomes a plan; the trainee sees a preview, approves it, and only then does the supervised skill run. The plans in the images were written by a local rule-based mock assistant.
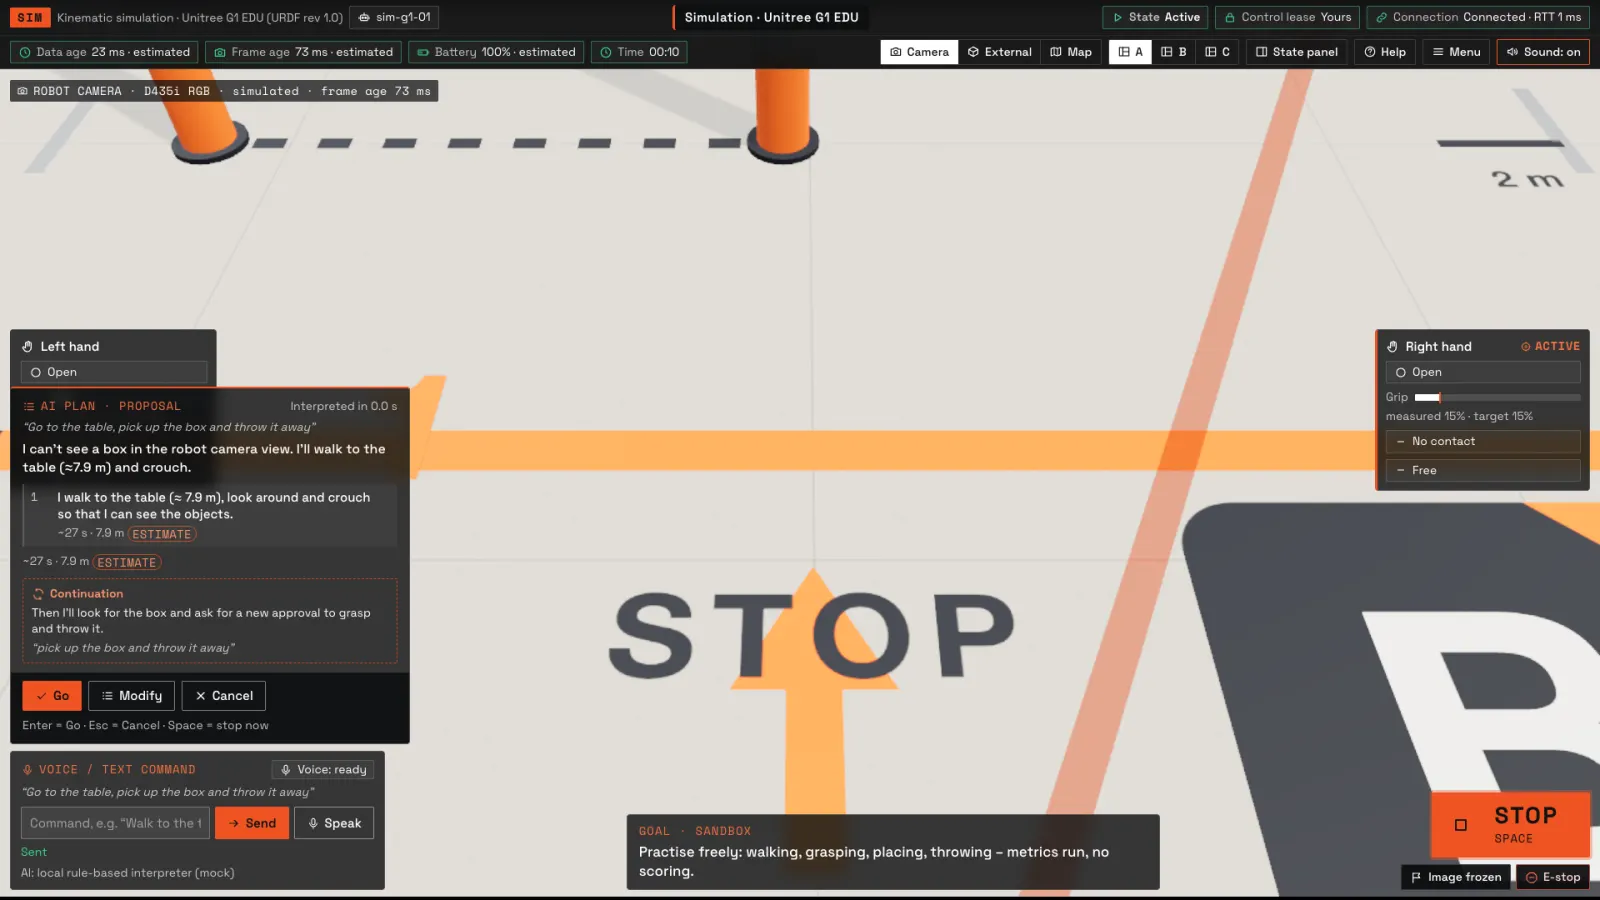 Simulation – real application recording
Sources
- 1X NEO — checked 2026-11-13
- ARworks R1 teleoperator training – README, test report, protocol (2026-11-17) — internal documentation, not public
Start a project
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.