
Mechanics and Kinematics
A robot is made of rigid links and joints. Degrees of freedom count the independent motion parameters of a body part.
How it works
A joint can be rotary or linear; each has an axis, a range and a speed limit. Hand DoF is stated separately from the body.
Material, mass and inertia affect balance, energy use and collisions. The same exterior can hide different dynamics.
What it means for teleoperation
The same hand gesture maps to different joint motion on different robots. Retargeting matches human and robot proportions.
For an unreachable target the system warns and limits the request – no jumps, no joint-limit violations.
Example from the training
The engineering view shows the G1’s collision capsules and joint table. The simulated robot moves within the joint limits of the official URDF.
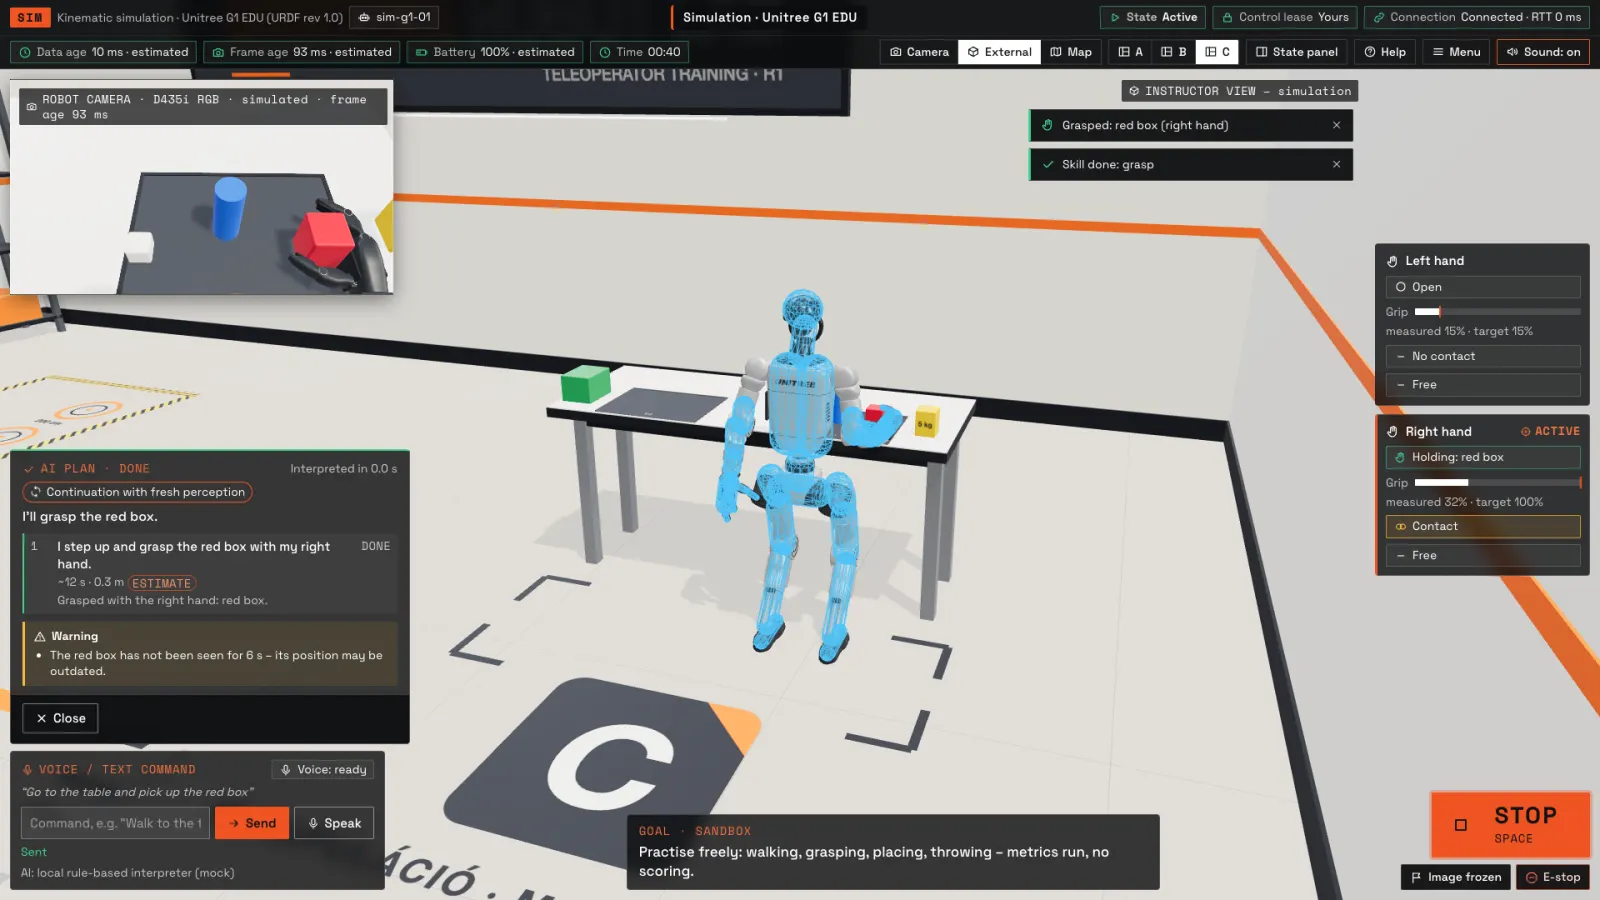 Simulation – real application recording
- Unitree G1 – manufacturer page — checked 2026-11-13
- Unitree unitree_mujoco — checked 2026-11-13
- Berkeley Humanoid Lite — checked 2026-11-13
- ARworks R1 teleoperator training – README, test report, protocol (2026-11-17) — internal documentation, not public
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.