
UC Berkeley – Hybrid Robotics
Berkeley Humanoid Lite
Open-source 0.8 m, 16 kg research humanoid from UC Berkeley with 3D-printed cycloidal gearboxes and off-the-shelf parts; the authors state a hardware cost under USD 5,000.
Catalog dataResearch platformBipedal humanoidOpen source
- Height
- 0.8 m
- Mass
- 16 kg
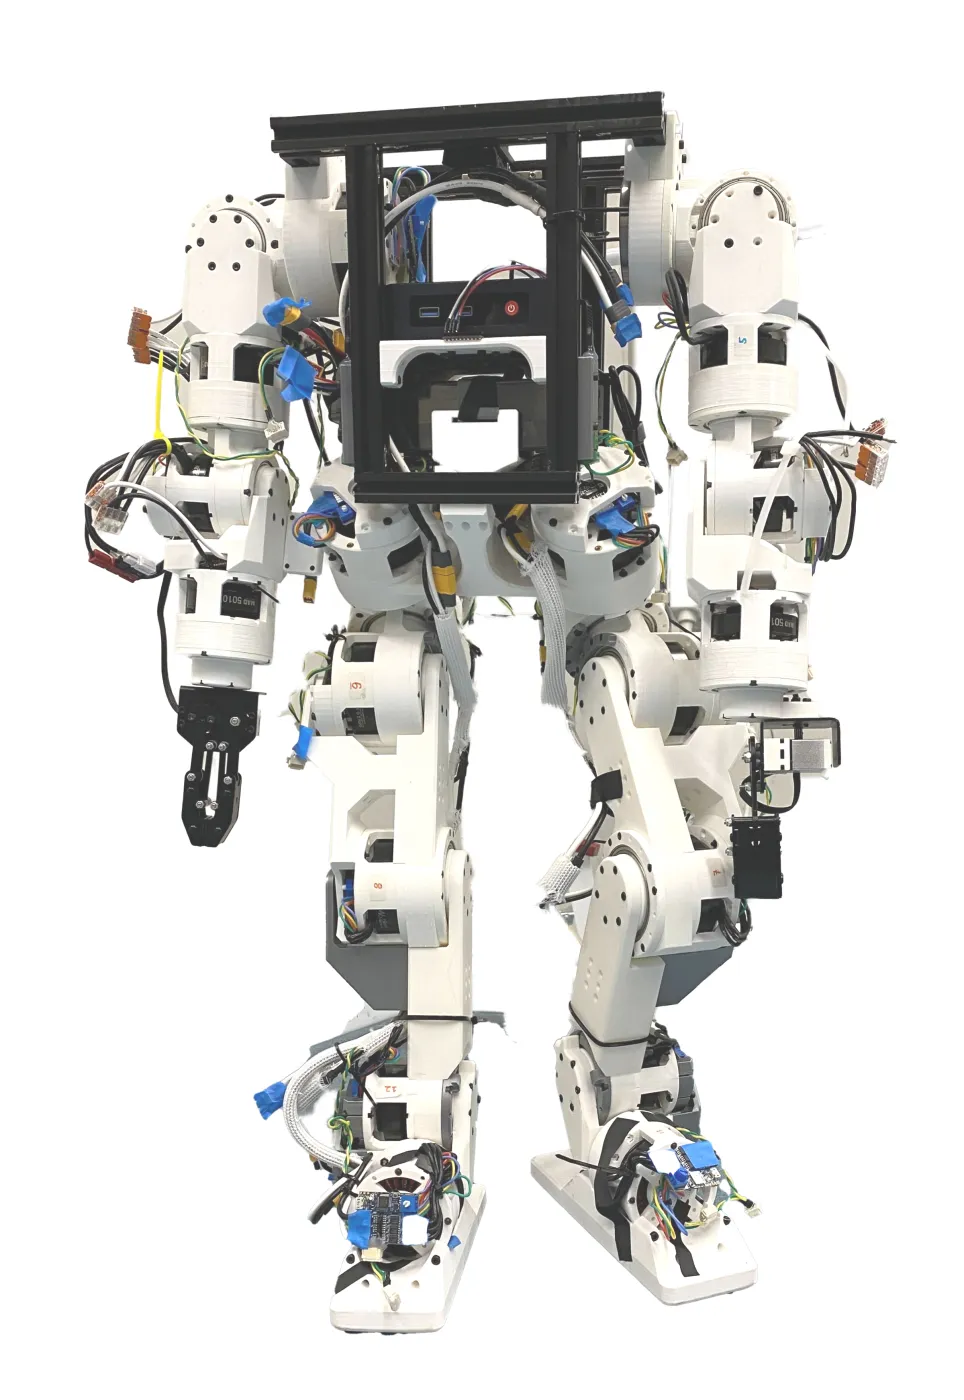 Image: © Hybrid Robotics, UC Berkeley (CC BY-SA 4.0)
ARworks
ARworks status by function
What works with this robot at ARworks today – and what does not.
Catalog data No ARworks integration for this robot: catalog data only. Integration follows a per-robot assessment.
Berkeley Humanoid Lite
Technical data
From manufacturer or primary sources. The superscript points to the source.
Geometry
Payload and locomotion
| Documented locomotion skills | Bipedal walking with a reinforcement-learning policy tracking user velocity commands; zero-shot sim-to-real transfer3 |
|---|
Actuators and hands
| Drive | Two modular actuator sizes (6512 and 5010): BLDC drone motor, 3D-printed cycloidal gearbox, B-G431B-ESC1 driver, AS5600 encoder; 1 Mbps CAN 2.0 bus per limb3 |
|---|---|
| Hand / gripper | Integrated gripper on each arm (2 in the BOM); the paper also shows an adult-size alternative configuration with a dexterous hand3 |
Sensing and compute
Energy and connectivity
Development
| SDK / API | Open codebase: Isaac Lab training environments, sim2sim validation, real-robot deployment, motion capture, teleoperated manipulation1 |
|---|---|
| Robot description files | URDF, MJCF and USD robot descriptions in berkeley_humanoid_lite_assets (exportable from Onshape)1 |
| Simulation | Training: NVIDIA Isaac Sim / Isaac Lab; sim2sim check: MuJoCo7 |
| License | Code: MIT; other assets (CAD, print files etc.): CC BY-SA 4.01 |
Size
Editorial notes
- The project publishes no total DoF, so we did not compute one; per-leg and per-arm values are in the table.
Sources
- Berkeley Humanoid Lite (GitHub repository, README) — Hybrid Robotics, UC Berkeley · checked 2026-11-17
- Berkeley Humanoid Lite: An Open-source, Accessible, and Customizable 3D-printed Humanoid Robot (project page) — Hybrid Robotics, UC Berkeley · checked 2026-11-17
- Demonstrating Berkeley Humanoid Lite (RSS 2025 paper; arXiv 2504.17249) — Chi et al., UC Berkeley · checked 2026-11-17
- Joint ID Mapping – Berkeley Humanoid Lite Docs — Hybrid Robotics, UC Berkeley · checked 2026-11-17
- Releases – Berkeley Humanoid Lite Docs — Hybrid Robotics, UC Berkeley · checked 2026-11-17
- IMU Comparision – Berkeley Humanoid Lite Docs — Hybrid Robotics, UC Berkeley · checked 2026-11-17
- Training Environment – Berkeley Humanoid Lite Docs — Hybrid Robotics, UC Berkeley · checked 2026-11-17
- Sim2sim Validation – Berkeley Humanoid Lite Docs — Hybrid Robotics, UC Berkeley · checked 2026-11-17
Data sheet last checked: 2026-11-17 · USA · Manufacturer names and images belong to their owners. Being listed in the catalog implies no partnership or integration.
Start a project
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.