
Stanford University
ToddlerBot
Open-source 0.56 m, 3.4 kg miniature humanoid from Stanford University; 30 active DoF, Dynamixel servos, 3D-printed body, built for machine-learning research on loco-manipulation.
Catalog dataResearch platformBipedal humanoidOpen source
- Height
- 0.56 m
- Mass
- 3.4 kg
- Total DoF
- 30
- Payload
- 1.484 kg
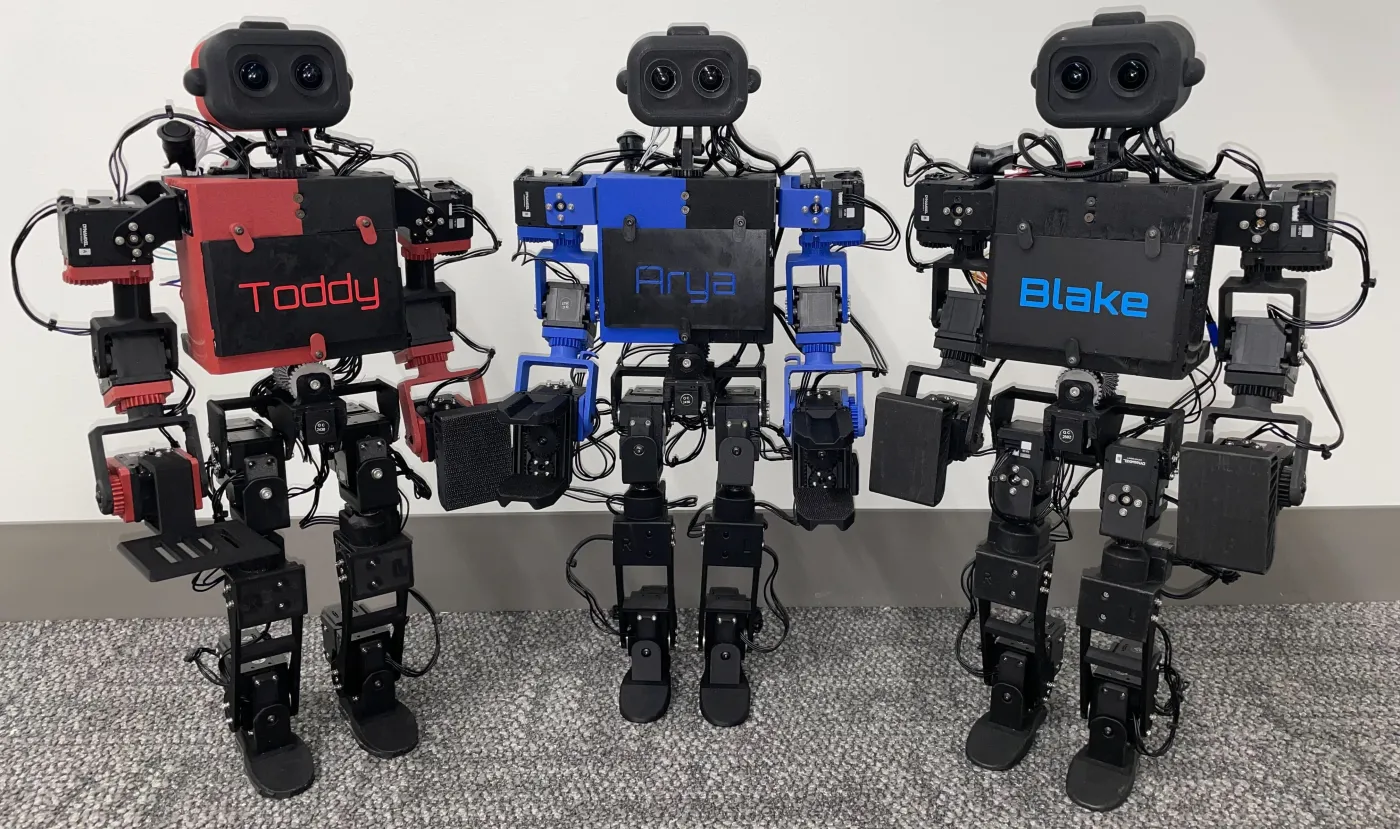 Image: © ToddlerBot, Stanford University
ARworks
ARworks status by function
What works with this robot at ARworks today – and what does not.
Catalog data No ARworks integration for this robot: catalog data only. Integration follows a per-robot assessment.
ToddlerBot
Technical data
From manufacturer or primary sources. The superscript points to the source.
Geometry
| Variant | ToddlerBot (toddlerbot_2xc, default)recommended default version (same motors as v1.0); values per paper (arXiv v4) and project page | ToddlerBot (toddlerbot_2xm)2.0 version with upgraded hip and arm motors; no other differing values published |
|---|---|---|
| Generation / revision | Release 2.0.0 (2025-08-25); initial release 2025-02-03; two hardware versions: toddlerbot_2xc and toddlerbot_2xm2 | Release 2.0.0 (2025-08-25), optional stronger version alongside toddlerbot_2xc6 |
| Height | 0.56 m4 | Not published |
| Mass | 3.4 kg4 | Not published |
Kinematics
| Variant | ToddlerBot (toddlerbot_2xc, default)recommended default version (same motors as v1.0); values per paper (arXiv v4) and project page | ToddlerBot (toddlerbot_2xm)2.0 version with upgraded hip and arm motors; no other differing values published |
|---|---|---|
| Total DoF | 303 | Not published |
| DoF per leg | 63 | Not published |
| DoF per arm | 73 | Not published |
| Waist | 23 | Not published |
Payload and locomotion
| Variant | ToddlerBot (toddlerbot_2xc, default)recommended default version (same motors as v1.0); values per paper (arXiv v4) and project page | ToddlerBot (toddlerbot_2xm)2.0 version with upgraded hip and arm motors; no other differing values published |
|---|---|---|
| Payload | 1.484 kg3 | Not published |
| Walking speed | 0.25 m/s3 | Not published |
| Documented locomotion skills | Omnidirectional walking with RL (zero-shot sim-to-real), crawling, cartwheel, push-ups, pull-ups (keyframe animation)3 | Not published |
Actuators and hands
| Variant | ToddlerBot (toddlerbot_2xc, default)recommended default version (same motors as v1.0); values per paper (arXiv v4) and project page | ToddlerBot (toddlerbot_2xm)2.0 version with upgraded hip and arm motors; no other differing values published |
|---|---|---|
| Drive | Robotis Dynamixel servos (XC330-T288, XC430-T240BB, XM430-W210, 2XL430-W250, 2XC430-W250) with spur-gear, bevel-gear and linkage transmissions4 | Dynamixel servos with upgraded hip and arm motors (hip: 2XM430-W350 instead of 2XC430)2 |
| Hand / gripper | Two swappable end effectors: parallel-jaw gripper (XC330 servo) and compliant palm; swap within about two minutes4 | Not published |
Sensing and compute
| Variant | ToddlerBot (toddlerbot_2xc, default)recommended default version (same motors as v1.0); values per paper (arXiv v4) and project page | ToddlerBot (toddlerbot_2xm)2.0 version with upgraded hip and arm motors; no other differing values published |
|---|---|---|
| Vision | Two fisheye cameras in the head for a wider field of view4 | Not published |
| Other sensing | IMU in the chest, two microphones, one speaker4 | Not published |
| Onboard compute | NVIDIA Jetson Orin NX 16GB (real-time ML inference)4 | Not published |
Energy and connectivity
| Variant | ToddlerBot (toddlerbot_2xc, default)recommended default version (same motors as v1.0); values per paper (arXiv v4) and project page | ToddlerBot (toddlerbot_2xm)2.0 version with upgraded hip and arm motors; no other differing values published |
|---|---|---|
| Battery capacity | 2 Ah4 | Not published |
| Nominal voltage | 14.8 V4 | Not published |
| Runtime | 3–5 h4 | Not published |
| Connectivity | Wi-Fi card on the Jetson Orin (SSH access)5 | Not published |
Development
| Variant | ToddlerBot (toddlerbot_2xc, default)recommended default version (same motors as v1.0); values per paper (arXiv v4) and project page | ToddlerBot (toddlerbot_2xm)2.0 version with upgraded hip and arm motors; no other differing values published |
|---|---|---|
| SDK / API | Full pip-installable Python codebase: low-level control, RL and diffusion-policy training, real-world deployment1 | Not published |
| Robot description files | URDF and MJCF descriptions with an Onshape-to-MJCF pipeline2 | Not published |
| Simulation | MuJoCo / MJX (RL training with rsl_rl and Brax, terrain generation)2 | Not published |
| License | Code and documentation: MIT; hardware design (Onshape, STL etc.): CC BY-NC-SA 4.0 (non-commercial)1 | Not published |
Size
Editorial notes
- The 0.56 m height may refer to the first version; the 2.0 legs are 30 mm shorter.
- The paper mentions three runtimes (3–5 h, about 2 h, 19 min of continuous walking); the table states the condition.
- The hardware design license is non-commercial (CC BY-NC-SA 4.0).
Sources
- ToddlerBot (GitHub repository, README) — ToddlerBot team, Stanford University · checked 2026-11-17
- ToddlerBot CHANGELOG ([2.0.0] - 2025-08-25) — ToddlerBot team, Stanford University · checked 2026-11-17
- ToddlerBot: Open-Source ML-Compatible Humanoid Platform for Loco-Manipulation (project page, CoRL 2025) — ToddlerBot team, Stanford University · checked 2026-11-17
- ToddlerBot: Open-Source ML-Compatible Humanoid Platform for Loco-Manipulation (arXiv 2502.00893v4, 2025-10-06) — Shi, Wang, Song, Liu – Stanford University · checked 2026-11-17
- Jetson Orin – toddlerbot documentation — ToddlerBot team, Stanford University · checked 2026-11-17
- Bill of Materials – toddlerbot documentation — ToddlerBot team, Stanford University · checked 2026-11-17
Data sheet last checked: 2026-11-17 · USA · Manufacturer names and images belong to their owners. Being listed in the catalog implies no partnership or integration.
Start a project
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.