
OpenLoong
OpenLoong Qinglong
Open-source full-size (1.85 m, 80 kg) humanoid reference platform with 43 active DoF; its hardware drawings, control software and datasets are published by the OpenLoong community.
Catalog dataResearch platformBipedal humanoidOpen source
- Height
- 1.85 m
- Mass
- 80 kg
- Total DoF
- 43
- Payload
- 20 kg
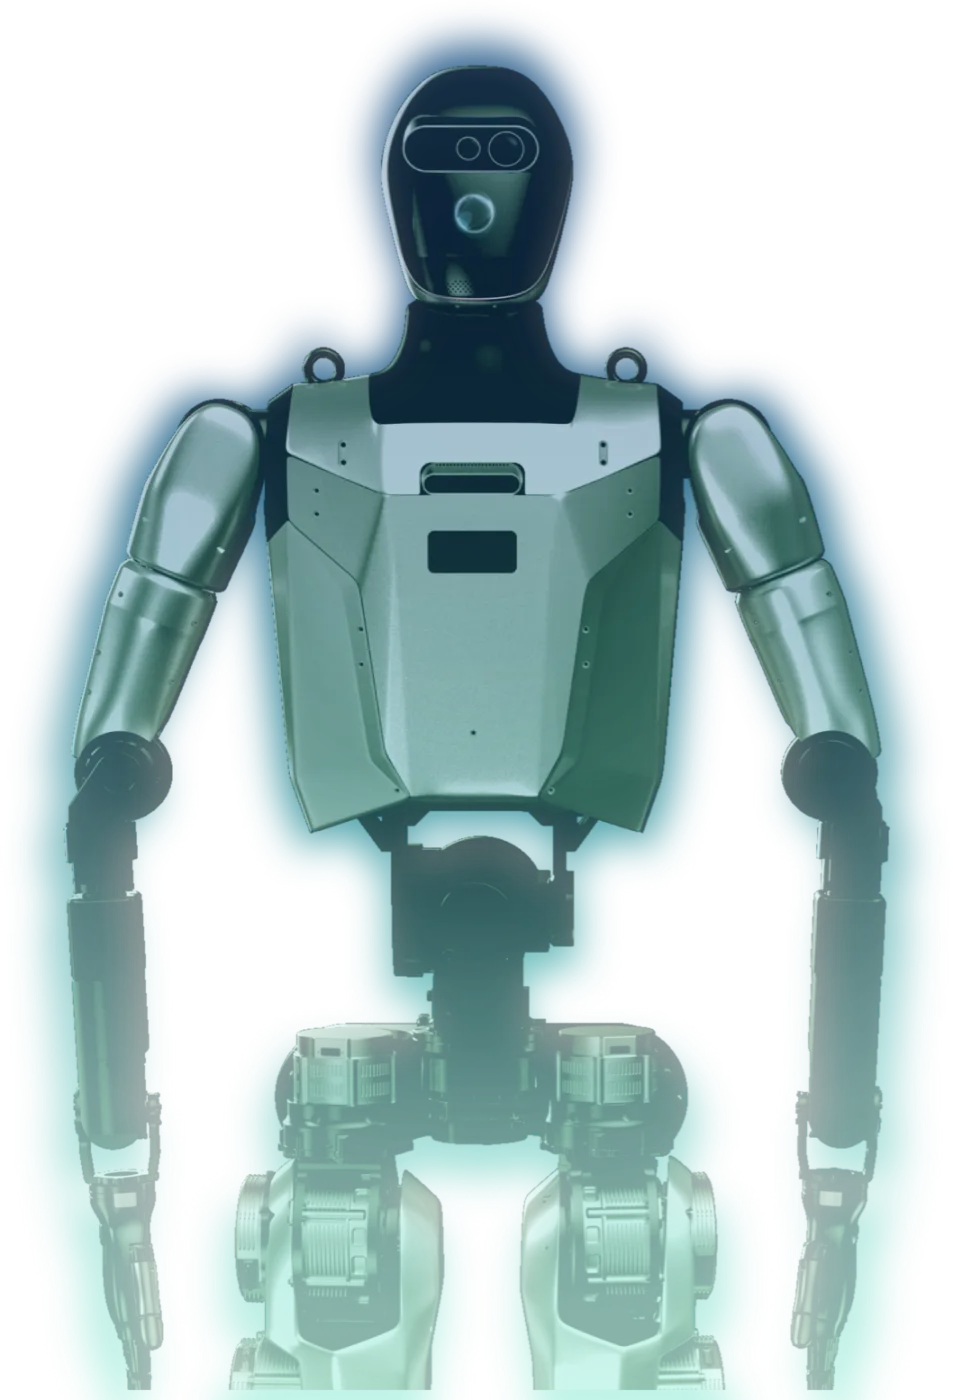 Image: © OpenLoong (openloong.org.cn)
ARworks
ARworks status by function
What works with this robot at ARworks today – and what does not.
Catalog data No ARworks integration for this robot: catalog data only. Integration follows a per-robot assessment.
OpenLoong Qinglong
Technical data
From manufacturer or primary sources. The superscript points to the source.
Geometry
Payload and locomotion
Actuators and hands
| Drive | EtherCAT joint drives (servo controller 11–95 V DC, ≥130 A, current loop ≥10 kHz); peak torque per joint 11.5–396 N·m2 |
|---|---|
| Max joint torque | 396 N·m2 |
| Hand / gripper | Modular quick-change dexterous hand (left/right): 19 DoF, 6 active; tactile sensor arrays in fingertips and palm; ≤600 g, hand payload ≥5 kg, 8.4 V2 |
Sensing and compute
| Vision | Depth vision sensor in the head; front and rear depth cameras at the waist (640×400@30 fps, FOV 80.5°×55.2°); four 120° 1920×1080 surround cameras at the waist2 |
|---|---|
| Other sensing | 3D LiDAR (chest/neck), depth cameras, voice module, olfactory sensor, surround cameras, MEMS sensor in the control computer, tactile sensing in the hands2 |
| Onboard compute | Motion-control computer with up to 400 TOPS AI compute; 4× gigabit Ethernet, 8× CAN, ≥6× USB3, RS422/RS232; EtherCAT bus to the joints2 |
Energy and connectivity
Development
| SDK / API | OpenLoong-Dyn-Control: open-source MPC + WBC motion-control framework (C++) with walking, jumping and blind obstacle-stepping examples4 |
|---|---|
| Robot description files | AzureLoong.urdf and MJCF (AzureLoong.xml) models in the OpenLoong-Dyn-Control models folder5 |
| Simulation | MuJoCo (walking, jumping and blind obstacle-stepping demos in OpenLoong-Dyn-Control)4 |
| License | Hardware: Solderpad Hardware License v2.1 (wraps Apache-2.0); software: mostly Apache-2.06 |
Size
Editorial notes
- Many values are published as minimums (≥); these carry a note.
- The sources disagree: battery 2052 Wh (homepage) vs at least 30 Ah at 72 V (hardware docs); dual-arm payload at least 5 vs at least 10 kg.
Sources
- QingLoong Full-Size Universal Humanoid Robot Hardware Open-Source Content (OpenLoong-Hardware repository, README + QingLoong V2.5 folder) — OpenLoong / Humanoid Robot (Shanghai) Co., Ltd. · checked 2026-11-17
- 青龙全尺寸通用人形机器人硬件开源内容 (technical document PDF, 25 pp.) — Humanoid Robot (Shanghai) Co., Ltd. · checked 2026-11-17
- 青龙·公版机 | OpenLoong (project page) — OpenLoong / Humanoid Robot (Shanghai) Co., Ltd. · checked 2026-11-17
- OpenLoong Dynamics Control (GitHub repository, README) — OpenLoong / Humanoid Robot (Shanghai) Co., Ltd. · checked 2026-11-17
- OpenLoong-Dyn-Control models folder (AzureLoong URDF / MJCF) — OpenLoong / Humanoid Robot (Shanghai) Co., Ltd. · checked 2026-11-17
- OpenLoong-Hardware license (Solderpad Hardware License v2.1) — Humanoid Robot (Shanghai) Co., Ltd. · checked 2026-11-17
- 人形机器人(上海)有限公司官网 (company homepage) — Humanoid Robot (Shanghai) Co., Ltd. · checked 2026-11-17
Data sheet last checked: 2026-11-17 · China · Manufacturer names and images belong to their owners. Being listed in the catalog implies no partnership or integration.
Start a project
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.