
Robot Technology Explained
Vision and Hearing
The operator sees what the robot’s camera sees. A VR headset’s wide field of view does not change that.
How it works
A single camera gives less depth than a stereo one. Frame rate, compression, exposure and latency together decide usability.
Spatial hearing needs a suitable microphone array; a mono stream gives no full spatial sound field.
What it means for teleoperation
With a fixed-camera robot, turning your head gives no new real side view. The display follows the actual sensor profile.
Example from the training
Example from the training
In robot-eye view you see the real window of the G1’s D435i camera (69° × 42°, tilted 47.6° down) – from the start pad only the floor. The optional ~125° stereo head camera is partly estimated.
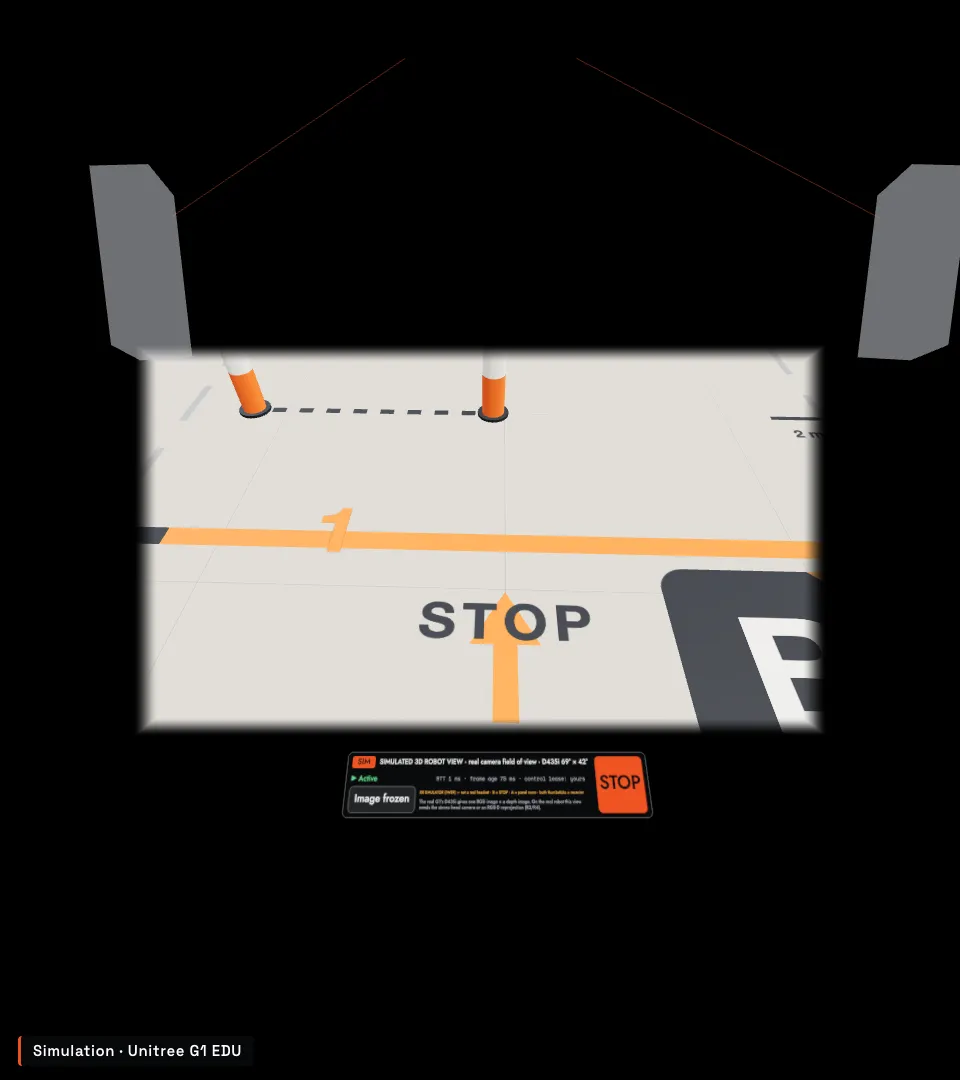 IWER emulator – not a real headset
Sources
- Unitree G1 – manufacturer page — checked 2026-11-13
- Unitree xr_teleoperate — checked 2026-11-13
- ARworks R1 teleoperator training – README, test report, protocol (2026-11-17) — internal documentation, not public
Start a project
Which robot, for what task?
Tell us the robot model, the use case and the working environment – we prepare the first meeting from that.